Film of LOLA (2010) @AppliedMechanicsTUM
Film of LOLA (2010)  @AppliedMechanicsTUM
Uploaded January 2017 | Updated September 2026, 1 hour ago
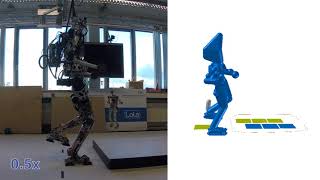
Fast, Robust and Autonomous Walking: demonstrating the initial capabilities of our Humanoid Robot "Lola".

Check out our open source repositories!
github.com/am-lola
Film of LOLA (2010)Humanoid Robot LOLA real time collision avoidanceReal-Time Hybrid Substructuring for Shock Applications Considering Effective Actuator ControlRobust and Versatile Bipedal Walking in Unknown EnvironmentsOpen Doors - 1973Hybrid Position/Force Control for Biped Robot Stabilization with Integrated Center of Mass DynamicsLOLA v1.1 - An Upgrade in Hardware and Software Design for Dynamic Multi-Contact LocomotionTest Rig Levitating in Active Magnetic BearingsSpherical Cubic Blends: Smooth Trajectory Generation with Quaternions (Presentation)First Movements of LOLA, our Humanoid RobotVision System of Humanoid Robot LOLA: Platforms and Dynamic ObstaclesNonlinear Optimization-Based Path Length Improvement
TUM Chair of Applied Mechanics |

Film of LOLA (2010)

SHARE TO X SHARE TO REDDIT SHARE TO FACEBOOK WALLPAPER