Uploaded July 2021 | Updated September 2026, 16 hours ago
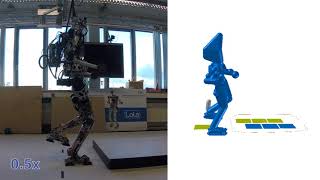
In this video we present our recent upgrades to the hard- and software of our humanoid robot LOLA. The changes were made in order to make LOLA capable of dynamic multi-contact locomotion (by which we mean additional hand-support during fast walking). This is meant to increase overall stability and robustness against model inaccuracies and disturbances.
This talk was held as oral presentation at the 2020 IEEE-RAS International Conference on Humanoid Robots (July 19-21 2021). For details, see the related conference paper "LOLA v1.1 - An Upgrade in Hardware and Software Design for Dynamic Multi-Contact Locomotion" by Philipp Seiwald, Shun-Cheng Wu, Felix Sygulla, Tobias Berninger, Nora-Sophie Staufenberg,
Moritz Sattler, Nicolas Neuburger, Daniel Rixen and Federico Tombari.
For more information on LOLA please see our project's website: mw.tum.de/en/am/research/current-projects/robotics/humanoid-robot-lola
This work is supported by the German Research Foundation (DFG, project number 407378162).
In this video we present our recent upgrades to the hard- and software of our humanoid robot LOLA. The changes were made in order to make LOLA capable of dynamic multi-contact locomotion (by which we mean additional hand-support during fast walking). This is meant to increase overall stability and robustness against model inaccuracies and disturbances.
This talk was held as oral presentation at the 2020 IEEE-RAS International Conference on Humanoid Robots (July 19-21 2021). For details, see the related conference paper "LOLA v1.1 - An Upgrade in Hardware and Software Design for Dynamic Multi-Contact Locomotion" by Philipp Seiwald, Shun-Cheng Wu, Felix Sygulla, Tobias Berninger, Nora-Sophie Staufenberg,
Moritz Sattler, Nicolas Neuburger, Daniel Rixen and Federico Tombari.
For more information on LOLA please see our project's website: mw.tum.de/en/am/research/current-projects/robotics/humanoid-robot-lola
This work is supported by the German Research Foundation (DFG, project number 407378162).