Uploaded October 2017 | Updated September 2026, 3 hours ago
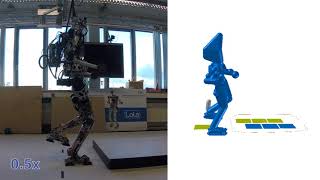
In this video, we test the capabilities of our Vision System and Motion Planning System, by letting the robot walk in previously unknown dynamic environments. The vision system approximates "walkable" surfaces as polygons and obstacles as capsules or spheres and the motion planning finds safe paths in real-time.
Check out our open source repositories!
github.com/am-lola
In this video, we test the capabilities of our Vision System and Motion Planning System, by letting the robot walk in previously unknown dynamic environments. The vision system approximates "walkable" surfaces as polygons and obstacles as capsules or spheres and the motion planning finds safe paths in real-time.
Check out our open source repositories!
github.com/am-lola