Uploaded January 2017 | Updated September 2026, 1 day ago
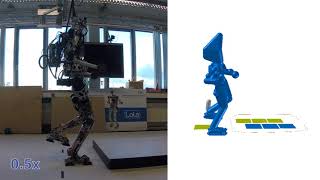
In this video, we show the combination of our vision, motion planning and stability modules on our humanoid robot Lola. This framework achieves autonomous biped navigation in unknown environments from simple walking commands.
Obstacles are modelled as one or more capsules. Then, the footsteps are planned by taking into account the obstacles' location and performing real-time 3D collision avoidance. While the robot is walking, its sensors watch out for un-modelled disturbances. To avoid falling down, footsteps locations are modified on-the-fly inside of collision-free regions.
Check out our open source repositories!
github.com/am-lola
In this video, we show the combination of our vision, motion planning and stability modules on our humanoid robot Lola. This framework achieves autonomous biped navigation in unknown environments from simple walking commands.
Obstacles are modelled as one or more capsules. Then, the footsteps are planned by taking into account the obstacles' location and performing real-time 3D collision avoidance. While the robot is walking, its sensors watch out for un-modelled disturbances. To avoid falling down, footsteps locations are modified on-the-fly inside of collision-free regions.
Check out our open source repositories!
github.com/am-lola