Uploaded July 2017 | Updated September 2026, 2 hours ago
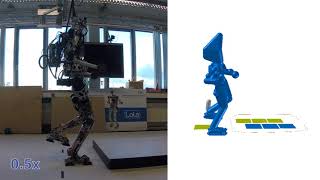
In this video we show the performance of a new force control approach for our humanoid LOLA. By using an explicit contact model and integrated CoM dynamics, we are able to walk from an unexpected platform of 5.5 cm height.
Check out our open source repositories!
github.com/am-lola
Check out our paper!
mediatum.ub.tum.de/node?id=1394924
In this video we show the performance of a new force control approach for our humanoid LOLA. By using an explicit contact model and integrated CoM dynamics, we are able to walk from an unexpected platform of 5.5 cm height.
Check out our open source repositories!
github.com/am-lola
Check out our paper!
mediatum.ub.tum.de/node?id=1394924