Uploaded March 2021 | Updated September 2026, 2 hours ago
Video for the IROS 2021 submission.
Preprint: arxiv.org/abs/2103.05903.
Code: github.com/ZJU-FAST-Lab/FAST-Dynamic-Vision.
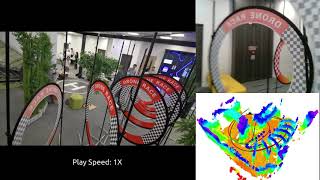
The development of aerial autonomy has enabled aerial robots to fly agilely in complex environments. However, dodging fast-moving objects in flight remains a challenge, limiting the further application of unmanned aerial vehicles(UAVs). The bottleneck of solving this problem is the accurate perception of rapid dynamic objects. Recently, event cameras have shown great potential in solving this problem. This paper presents a complete perception system including ego-motion compensation, object detection, and trajectory prediction for fast-moving dynamic objects with low latency and high precision. Firstly, we propose an accurate ego-motion compensation algorithm by considering both rotational and translational motion for more robust object detection. Then, for dynamic object detection, an event camera-based efficient regression algorithm is designed. Finally, we propose an optimization-based approach that asynchronously fuses event and depth cameras for trajectory prediction. Extensive real-world experiments and benchmarks are performed to validate our framework. Moreover, our code will be released to benefit related researches.
Video for the IROS 2021 submission.
Preprint: arxiv.org/abs/2103.05903.
Code: github.com/ZJU-FAST-Lab/FAST-Dynamic-Vision.
The development of aerial autonomy has enabled aerial robots to fly agilely in complex environments. However, dodging fast-moving objects in flight remains a challenge, limiting the further application of unmanned aerial vehicles(UAVs). The bottleneck of solving this problem is the accurate perception of rapid dynamic objects. Recently, event cameras have shown great potential in solving this problem. This paper presents a complete perception system including ego-motion compensation, object detection, and trajectory prediction for fast-moving dynamic objects with low latency and high precision. Firstly, we propose an accurate ego-motion compensation algorithm by considering both rotational and translational motion for more robust object detection. Then, for dynamic object detection, an event camera-based efficient regression algorithm is designed. Finally, we propose an optimization-based approach that asynchronously fuses event and depth cameras for trajectory prediction. Extensive real-world experiments and benchmarks are performed to validate our framework. Moreover, our code will be released to benefit related researches.