Uploaded September 2021 | Updated September 2026, 46 minutes ago
Video for the RAL submission.
Preprint: arxiv.org/abs/2109.04706
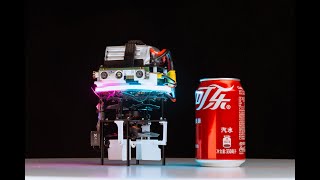
This letter presents a fully autonomous robot system that possesses both terrestrial and aerial mobility. We firstly develop a lightweight terrestrial-aerial quadrotor that carries sufficient sensing and computing resources. It incorporates both the high mobility of unmanned aerial vehicles and the long endurance of unmanned ground vehicles. An adaptive navigation framework is then proposed that brings complete autonomy to it. In this framework, a hierarchical motion planner is proposed to generate safe and low-power terrestrial-aerial trajectories in unknown environments. Moreover, we present a unified motion controller which dynamically adjusts energy consumption in terrestrial locomotion. Extensive real-world experiments and benchmark comparisons validate the proposed system’s robustness and outstanding performance. During the tests, it safely traverses complex environments with terrestrial-aerial integrated mobility, and achieves 7 energy savings in terrestrial locomotion. Finally, we will release our code and hardware configuration as an open-source package.
Video for the RAL submission.
Preprint: arxiv.org/abs/2109.04706
This letter presents a fully autonomous robot system that possesses both terrestrial and aerial mobility. We firstly develop a lightweight terrestrial-aerial quadrotor that carries sufficient sensing and computing resources. It incorporates both the high mobility of unmanned aerial vehicles and the long endurance of unmanned ground vehicles. An adaptive navigation framework is then proposed that brings complete autonomy to it. In this framework, a hierarchical motion planner is proposed to generate safe and low-power terrestrial-aerial trajectories in unknown environments. Moreover, we present a unified motion controller which dynamically adjusts energy consumption in terrestrial locomotion. Extensive real-world experiments and benchmark comparisons validate the proposed system’s robustness and outstanding performance. During the tests, it safely traverses complex environments with terrestrial-aerial integrated mobility, and achieves 7 energy savings in terrestrial locomotion. Finally, we will release our code and hardware configuration as an open-source package.