Uploaded August 2020 | Updated September 2026, 2 days ago
Video for the RA-L (accepted) with ICRA2021 option.
Preprint: arxiv.org/abs/2008.08835
Code: github.com/ZJU-FAST-Lab/ego-planner
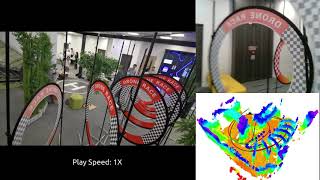
The gradient-based planner is widely used for quadrotor local planning, in which Euclidean Signed Distance Fields (ESDFs) is crucial for evaluating gradient magnitude and direction. Nevertheless, computing such a field contains significant redundancy since the trajectory optimization procedure only covers a very limited subspace of the ESDF updating range. In this paper, an ESDF-free gradient-based planning framework is proposed, which reduces computation time by an order of magnitude. The main improvement is that the collision term in penalty function is formulated by comparing the colliding trajectory with a collision-free guiding path. The resulting obstacle information will be stored only if the trajectory hits obstacles, so that the trajectory will rebound between nearby obstacles several times during optimizing. Then, we lengthen the time allocation if dynamical infeasibility is detected. An anisotropic curve fitting algorithm is introduced to adjust the higher-order derivatives of the trajectory while maintaining the original shape. Benchmark comparisons and real-world experiments verify its robustness and high-performance. The source code is released as ros-packages.
Video for the RA-L (accepted) with ICRA2021 option.
Preprint: arxiv.org/abs/2008.08835
Code: github.com/ZJU-FAST-Lab/ego-planner
The gradient-based planner is widely used for quadrotor local planning, in which Euclidean Signed Distance Fields (ESDFs) is crucial for evaluating gradient magnitude and direction. Nevertheless, computing such a field contains significant redundancy since the trajectory optimization procedure only covers a very limited subspace of the ESDF updating range. In this paper, an ESDF-free gradient-based planning framework is proposed, which reduces computation time by an order of magnitude. The main improvement is that the collision term in penalty function is formulated by comparing the colliding trajectory with a collision-free guiding path. The resulting obstacle information will be stored only if the trajectory hits obstacles, so that the trajectory will rebound between nearby obstacles several times during optimizing. Then, we lengthen the time allocation if dynamical infeasibility is detected. An anisotropic curve fitting algorithm is introduced to adjust the higher-order derivatives of the trajectory while maintaining the original shape. Benchmark comparisons and real-world experiments verify its robustness and high-performance. The source code is released as ros-packages.