Uploaded March 2023 | Updated September 2026, 55 minutes ago
Video for the IROS 2023 submission.
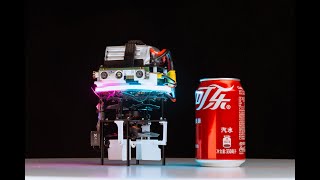
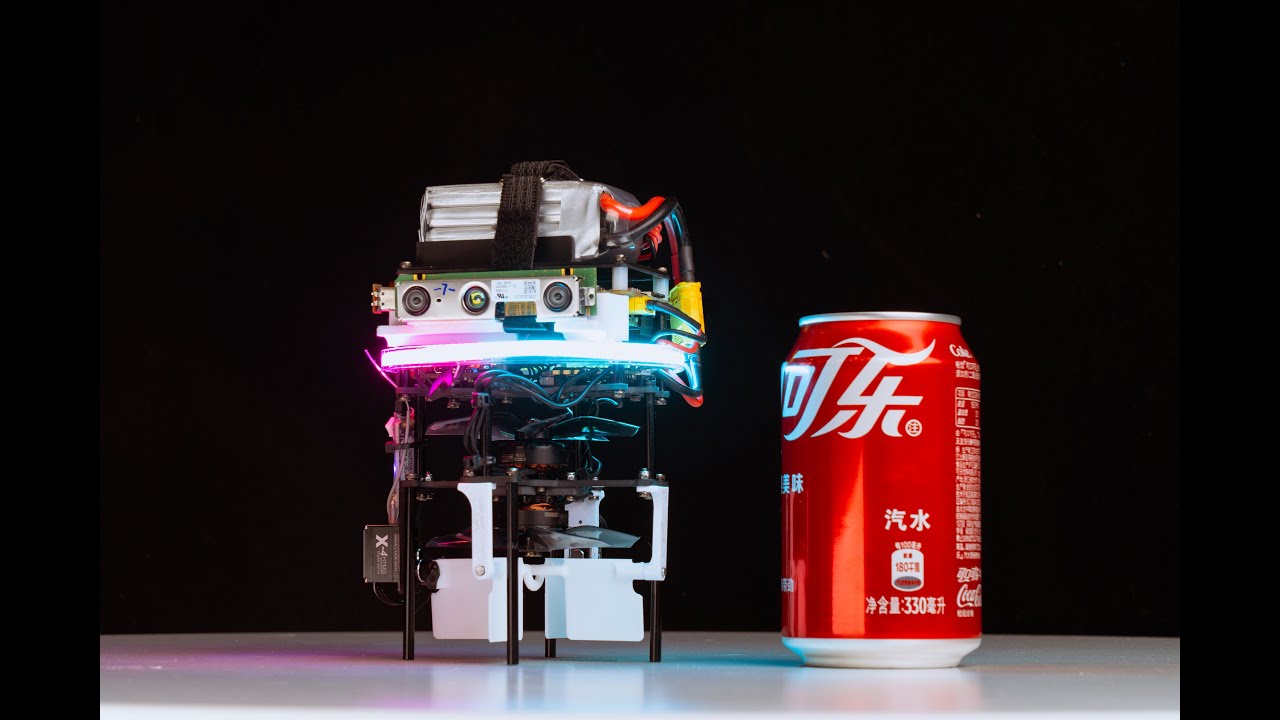
The video presents the paper "Canfly: A Can-sized Autonomous Mini Coaxial Helicopter".
The development of autonomous rotary-wing UAVs has shown an evident tendency in miniaturization. However, the side effects brought by miniaturization, such as decreased load capability, shorter flight duration, and reduced autonomous ability, seriously hinder the process. In this paper, we firstly investigate into the configuration of different rotary-wing aircraft and optimize the configuration selection. Afterward, with several elaborate mechanisms contributing for the miniaturization, we present the hardware design and control strategy of a mini coaxial helicopter, which is 62% smaller than the smallest autonomous quadrotor so far [1] in the collision area. Abundant experiments reveal that it achieves impressive traversability and is capable of carrying autonomous tasks in unknown dense scenarios, while maintaining satisfactory performance regarding loadability and flight duration.
Video for the IROS 2023 submission.
The video presents the paper "Canfly: A Can-sized Autonomous Mini Coaxial Helicopter".
The development of autonomous rotary-wing UAVs has shown an evident tendency in miniaturization. However, the side effects brought by miniaturization, such as decreased load capability, shorter flight duration, and reduced autonomous ability, seriously hinder the process. In this paper, we firstly investigate into the configuration of different rotary-wing aircraft and optimize the configuration selection. Afterward, with several elaborate mechanisms contributing for the miniaturization, we present the hardware design and control strategy of a mini coaxial helicopter, which is 62% smaller than the smallest autonomous quadrotor so far [1] in the collision area. Abundant experiments reveal that it achieves impressive traversability and is capable of carrying autonomous tasks in unknown dense scenarios, while maintaining satisfactory performance regarding loadability and flight duration.