Uploaded March 2023 | Updated September 2026, 51 minutes ago
Video for the IROS 2023 submission.
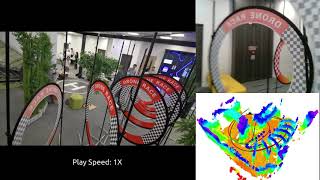
The video presents the experimental results of the paper "Continuous Implicit SDF Based Any-shape Robot Trajectory Optimization".
Optimization-based trajectory generation methods are widely used in whole-body planning for robots. However, existing work either oversimplifies the robot's geometry and environment representation, resulting in a conservative trajectory, or suffers from a huge overhead in maintaining additional information such as the Signed Distance Field (SDF). To bridge the gap, we consider the robot as an implicit function, with its surface boundary represented by the zero-level set of its SDF. Based on this, we further employ another implicit function to lazily compute the signed distance to the swept volume generated by the robot and its trajectory. The computation is efficient by exploiting continuity in space-time, and the implicit function guarantees precise and continuous collision evaluation even for nonconvex robots with complex surfaces. Furthermore, we propose a trajectory optimization pipeline applicable to the implicit SDF. Simulation and real-world experiments validate the high performance of our approach for arbitrarily shaped robot trajectory optimization.
Video for the IROS 2023 submission.
The video presents the experimental results of the paper "Continuous Implicit SDF Based Any-shape Robot Trajectory Optimization".
Optimization-based trajectory generation methods are widely used in whole-body planning for robots. However, existing work either oversimplifies the robot's geometry and environment representation, resulting in a conservative trajectory, or suffers from a huge overhead in maintaining additional information such as the Signed Distance Field (SDF). To bridge the gap, we consider the robot as an implicit function, with its surface boundary represented by the zero-level set of its SDF. Based on this, we further employ another implicit function to lazily compute the signed distance to the swept volume generated by the robot and its trajectory. The computation is efficient by exploiting continuity in space-time, and the implicit function guarantees precise and continuous collision evaluation even for nonconvex robots with complex surfaces. Furthermore, we propose a trajectory optimization pipeline applicable to the implicit SDF. Simulation and real-world experiments validate the high performance of our approach for arbitrarily shaped robot trajectory optimization.