Uploaded November 2016 | Updated September 2026, 7 hours ago
Check out our publication:
mediatum.ub.tum.de/node?id=1335426
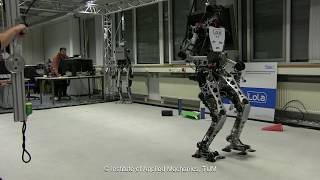
In this video, we show how our humanoid robot Lola models unexpected obstacles and avoids them in real time.
Each step, the following 6 steps are pre-calculated, and the 3D-motion of the robot is integrated to check for potential collisions with the environment.
Check out our open source repositories!
github.com/am-lola
Check out our publication:
mediatum.ub.tum.de/node?id=1335426
In this video, we show how our humanoid robot Lola models unexpected obstacles and avoids them in real time.
Each step, the following 6 steps are pre-calculated, and the 3D-motion of the robot is integrated to check for potential collisions with the environment.
Check out our open source repositories!
github.com/am-lola