Uploaded October 2015 | Updated September 2026, 2 hours ago
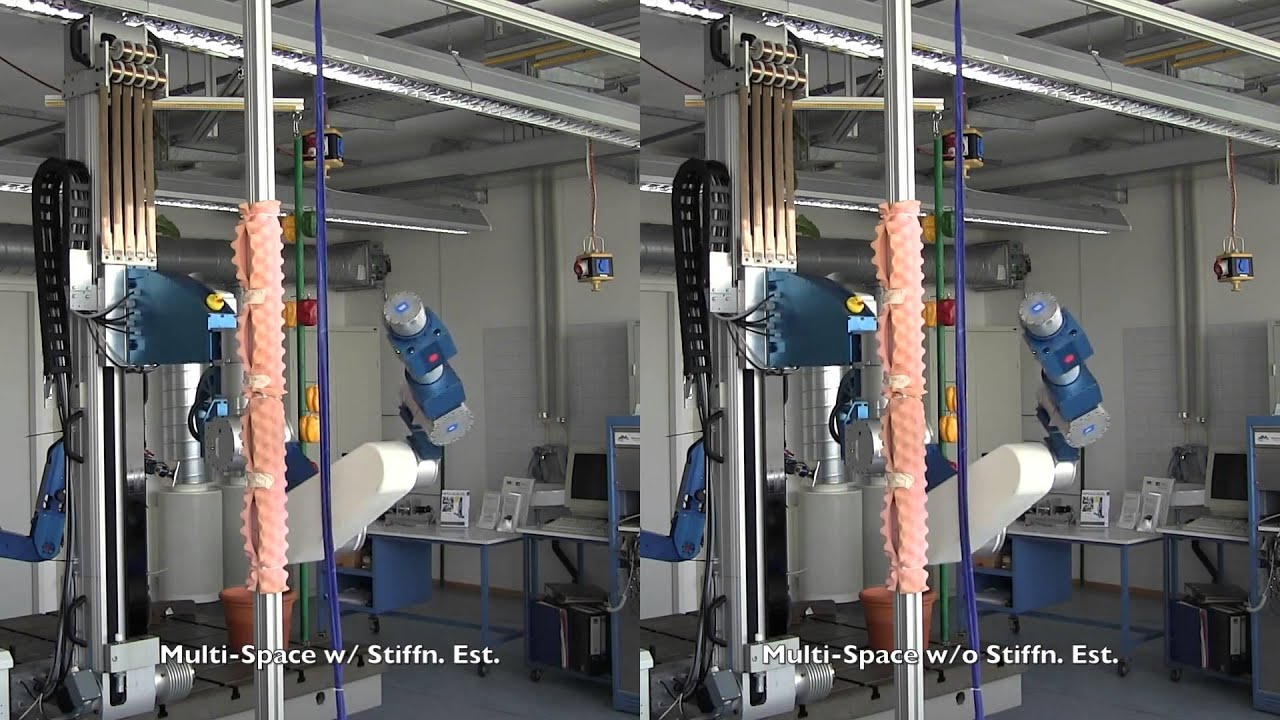
The video shows two different control concepts for motion planning with tactile feedback on the CROPS manipulator (2015). In all scenarios, a straight line path of the TCP is commanded.
However, the robot may deviate from the desired trajectory if high contact forces with the environment occur. With the flexible framework developed at the institute, the effects of the trade-off between low contact forces and good positional tracking can be resolved by adaptive motion planning based on the current situation.
Furthermore, we show that the use of an online stiffness estimation makes the algorithm robust for scenarios with objects of highly different stiffness.
The video shows two different control concepts for motion planning with tactile feedback on the CROPS manipulator (2015). In all scenarios, a straight line path of the TCP is commanded.
However, the robot may deviate from the desired trajectory if high contact forces with the environment occur. With the flexible framework developed at the institute, the effects of the trade-off between low contact forces and good positional tracking can be resolved by adaptive motion planning based on the current situation.
Furthermore, we show that the use of an online stiffness estimation makes the algorithm robust for scenarios with objects of highly different stiffness.