Humanoid Robot LOLA at the Hannover Fair 2010 @AppliedMechanicsTUM
Humanoid Robot LOLA at the Hannover Fair 2010  @AppliedMechanicsTUM
Uploaded March 2015 | Updated September 2026, 21 hours ago
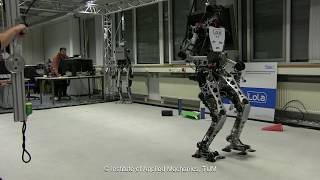
Presentation of our Humanoid Robot "Lola" at the Hannover Messe 2010.

Check out our open source repositories!
github.com/am-lola
Humanoid Robot LOLA at the Hannover Fair 2010A Mobile Dual-Arm System That Makes Intralogistics More EfficientOur Humanoid Robot LOLA pre-simulates motions to better walk over complicated terrainTeleoperation with an Agricultural Robot - collision and joint limit avoidanceHierarchical Control of First-Order Differential KinematicsCROPS Manipulator (Generation 2) picking sweet-pepper in greenhouseCROPS Manipulator (Generation 1) - Self Collision AvoidanceAutomatic swing - a parametric oscillatorCROPS Manipulator (Generation 2) in 7 DOF configuration picking sweet-pepper in labHumanoid Robot LOLA stepping on unmodelled obstaclesSpherical Cubic Blends: Smooth Trajectory Generation with QuaternionsStereoscopic High Speed Camera Based Operational Modal Analysis using a One-Camera Setup
TUM Chair of Applied Mechanics |

Humanoid Robot LOLA at the Hannover Fair 2010

SHARE TO X SHARE TO REDDIT SHARE TO FACEBOOK WALLPAPER