Uploaded August 2023 | Updated November 2026, 3 hours ago
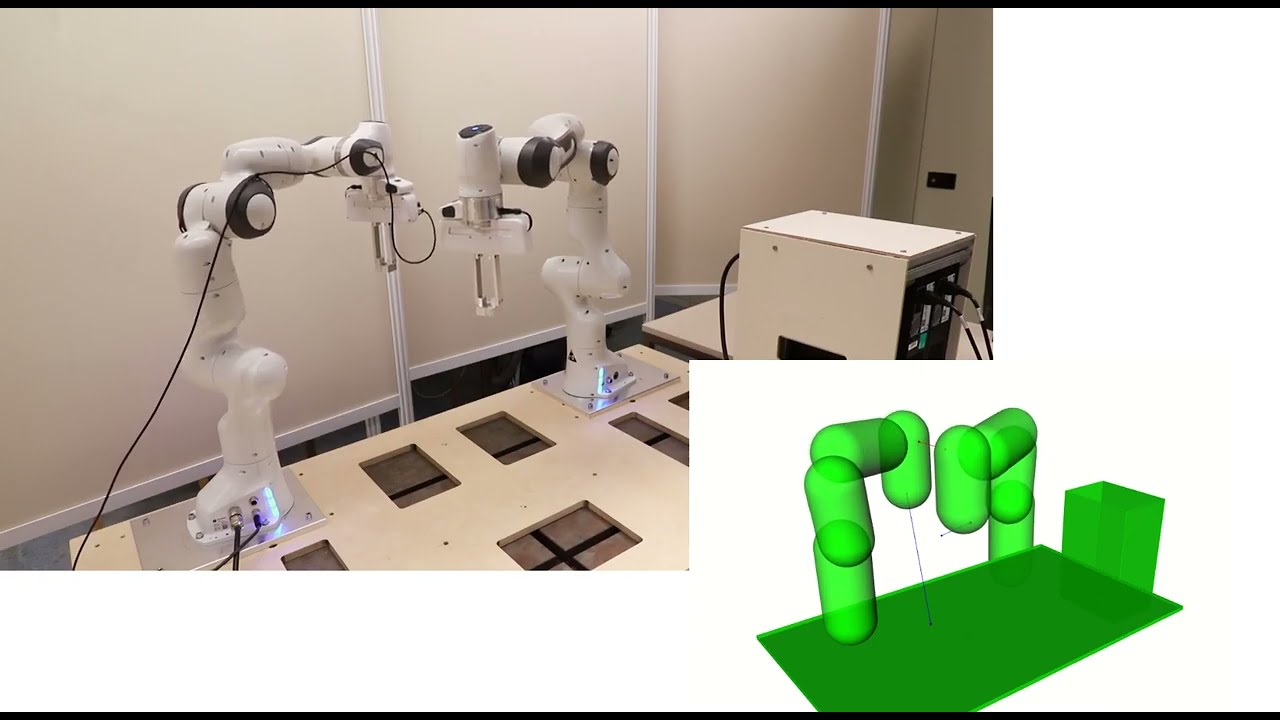
This video shows an experiment and a simulation. Both use our developed first-order hierarchical control approach. However, the experiment uses continuous task repriorization and the simulation uses discrete task repriorization.
The experiment demonstrates that our approach with continuous task repriorization leads to continuous joint velocity control commands.
The simulation shows that the approach with discrete task repriorization leads to discontinuous joint velocity control commands that can not be executed on the real robot.
This video shows an experiment and a simulation. Both use our developed first-order hierarchical control approach. However, the experiment uses continuous task repriorization and the simulation uses discrete task repriorization.
The experiment demonstrates that our approach with continuous task repriorization leads to continuous joint velocity control commands.
The simulation shows that the approach with discrete task repriorization leads to discontinuous joint velocity control commands that can not be executed on the real robot.


