Uploaded December 2023 | Updated September 2026, 5 hours ago
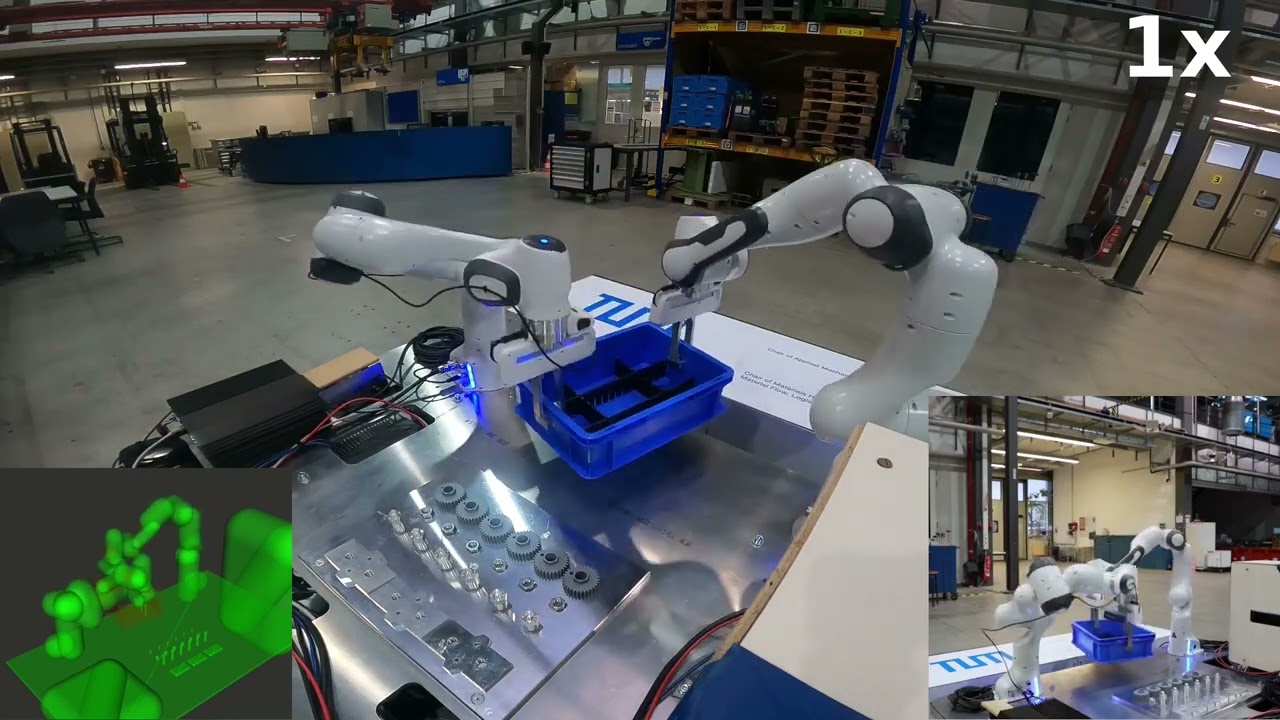
This video shows the mobile dual-arm system we have developed. The two robot arms perform manipulation tasks during transport, making intralogistics more efficient. We worked on the synchronization of the two robot arms and investigated the impact of the platform dynamics on the control of the two robot arms. Our project partner youtube.com/@fmlTUMunich worked on the autonomous navigation of the mobile platform and developed robust task planning with error recovery strategies.
This video shows the mobile dual-arm system we have developed. The two robot arms perform manipulation tasks during transport, making intralogistics more efficient. We worked on the synchronization of the two robot arms and investigated the impact of the platform dynamics on the control of the two robot arms. Our project partner youtube.com/@fmlTUMunich worked on the autonomous navigation of the mobile platform and developed robust task planning with error recovery strategies.