Uploaded April 2024 | Updated September 2026, 7 hours ago
Advances in prosthetic evaluation have been achieved through a joint project with the IPD CAD Lab at the University of Maribor and the Chair of Applied Mechanics at the Technical University of Munich.
Exciting possibilities in prosthetics are emerging through additive manufacturing, especially with the advent of 3D printing, which enables personalized and cost-effective production. The IPD CAD Lab focuses on the advancement of 3D printing for lower limb prostheses.
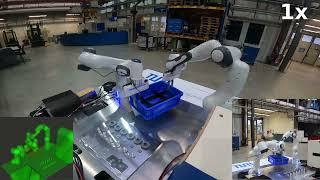
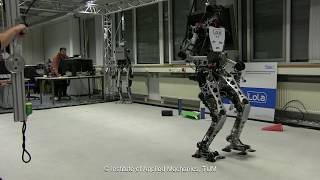
A novel testing approach is being pursued to evaluate lower limb prostheses using a robotic arm. In this approach, a cyclic gait motion is simulated by a robotic arm to test durability. Both a prosthetic limb and a 3D printed footprosthesis are mounted on the robot for testing. The gait trajectory for the robot is taken from walking lab data, and the force signals are monitored to detect potential failures.
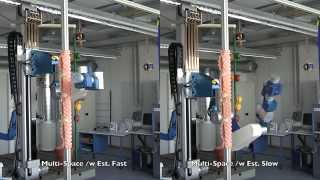
While initially relying on pre-recorded gait data, our collaboration works towards the exploration of Real-Time Hybrid Substructuring (RTHS) for prosthesis testing, a method previously investigated at the Chair of Applied Mechanics. This approach promises more adaptable and versatile testing techniques. First steps have been taken with simple 1-dimensional mass spring damper experiments using the industrial robot. However, further research is needed before fully implementing an RTHS approach in prosthesis testing.
In summary, this collaborative effort is making significant strides in prosthesis evaluation through the integration of robotics and innovative testing techniques. Stay tuned for updates on this research journey!
Advances in prosthetic evaluation have been achieved through a joint project with the IPD CAD Lab at the University of Maribor and the Chair of Applied Mechanics at the Technical University of Munich.
Exciting possibilities in prosthetics are emerging through additive manufacturing, especially with the advent of 3D printing, which enables personalized and cost-effective production. The IPD CAD Lab focuses on the advancement of 3D printing for lower limb prostheses.
A novel testing approach is being pursued to evaluate lower limb prostheses using a robotic arm. In this approach, a cyclic gait motion is simulated by a robotic arm to test durability. Both a prosthetic limb and a 3D printed footprosthesis are mounted on the robot for testing. The gait trajectory for the robot is taken from walking lab data, and the force signals are monitored to detect potential failures.
While initially relying on pre-recorded gait data, our collaboration works towards the exploration of Real-Time Hybrid Substructuring (RTHS) for prosthesis testing, a method previously investigated at the Chair of Applied Mechanics. This approach promises more adaptable and versatile testing techniques. First steps have been taken with simple 1-dimensional mass spring damper experiments using the industrial robot. However, further research is needed before fully implementing an RTHS approach in prosthesis testing.
In summary, this collaborative effort is making significant strides in prosthesis evaluation through the integration of robotics and innovative testing techniques. Stay tuned for updates on this research journey!