Uploaded January 2017 | Updated September 2026, 1 hour ago
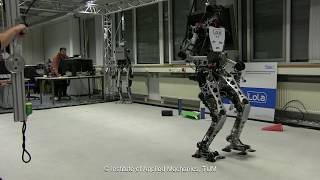
Vision-Based Autonomous Walking over Platforms or Stairs.
- Our vision system uses a kinect-like sensor to model the environment: surfaces (including the ground) are modelled as polygons and obstacles as SSV's (swept-sphere volumes).
- Our motion planning system uses a modified A* search algorithm to find footsteps locations on walkable surfaces and each step's parameters are optimized to account for kinematic capabilities.
Everything is running in real-time
Check out our open source repositories!
github.com/am-lola
Vision-Based Autonomous Walking over Platforms or Stairs.
- Our vision system uses a kinect-like sensor to model the environment: surfaces (including the ground) are modelled as polygons and obstacles as SSV's (swept-sphere volumes).
- Our motion planning system uses a modified A* search algorithm to find footsteps locations on walkable surfaces and each step's parameters are optimized to account for kinematic capabilities.
Everything is running in real-time
Check out our open source repositories!
github.com/am-lola