Uploaded August 2024 | Updated November 2026, 3 hours ago
This is one last test of the HEQ gimbal after I tried their new firmware. I ended up using their firmware to just help me go back to locking the yaw mechanically like I was before. It was the most reliable way for me to go about it without ever having to worry about random jitter. If this was just an on-road car then I would just outright use all 3 axes and set the holding torque higher.
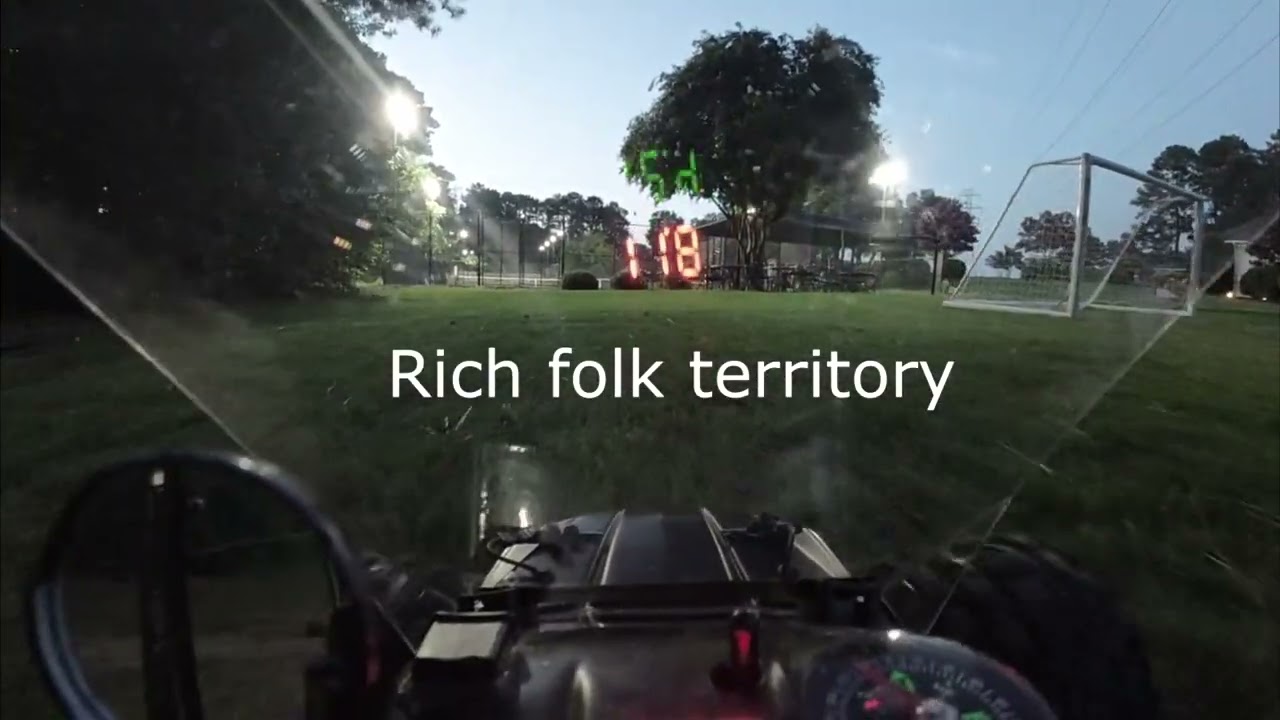
I also wanted to test how it would look driving around with a piece of thin polycarbonate sheet. It didn't work out so well because of the voltmeter reflection so I later put an angled cover over them to block that. I figured I would try to use a simple cover like that just to protect the gimbal from getting caught on things in the woods.
The new HEQ firmware comes with more features but it also allows you to adjust the motor holding torque from standard 10000 value up to 30000. I tested the gimbal out again with the torque all the way up and noticed most of the jitter went away and it was pretty smooth. It was almost perfect until I started going over rocks and sticks etc. I got tired of messing with it and just went back to locking the yaw and using my own servo. I figured since they now allow me to reduce the torque on the yaw then I can worry less about locking it.
I later realized there's probably a fix I have yet to try or maybe won't even try cause I don't care anymore. The gimbal is weighted such that the camera makes it front heavy. I think this is why it was struggling with the yaw a lot for me because it would easily sort of slingshot one way or the other. If the higher holding torque almost fixed it then maybe it just needs to be better balanced. I think I stacked a couple pennies or dimes on the back of it and thought it had about balanced out but I never tested that theory.
This is one last test of the HEQ gimbal after I tried their new firmware. I ended up using their firmware to just help me go back to locking the yaw mechanically like I was before. It was the most reliable way for me to go about it without ever having to worry about random jitter. If this was just an on-road car then I would just outright use all 3 axes and set the holding torque higher.
I also wanted to test how it would look driving around with a piece of thin polycarbonate sheet. It didn't work out so well because of the voltmeter reflection so I later put an angled cover over them to block that. I figured I would try to use a simple cover like that just to protect the gimbal from getting caught on things in the woods.
The new HEQ firmware comes with more features but it also allows you to adjust the motor holding torque from standard 10000 value up to 30000. I tested the gimbal out again with the torque all the way up and noticed most of the jitter went away and it was pretty smooth. It was almost perfect until I started going over rocks and sticks etc. I got tired of messing with it and just went back to locking the yaw and using my own servo. I figured since they now allow me to reduce the torque on the yaw then I can worry less about locking it.
I later realized there's probably a fix I have yet to try or maybe won't even try cause I don't care anymore. The gimbal is weighted such that the camera makes it front heavy. I think this is why it was struggling with the yaw a lot for me because it would easily sort of slingshot one way or the other. If the higher holding torque almost fixed it then maybe it just needs to be better balanced. I think I stacked a couple pennies or dimes on the back of it and thought it had about balanced out but I never tested that theory.