Uploaded June 2022 | Updated September 2026, 1 week ago
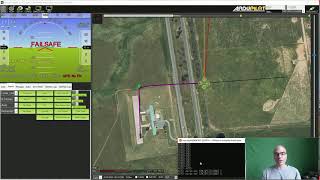
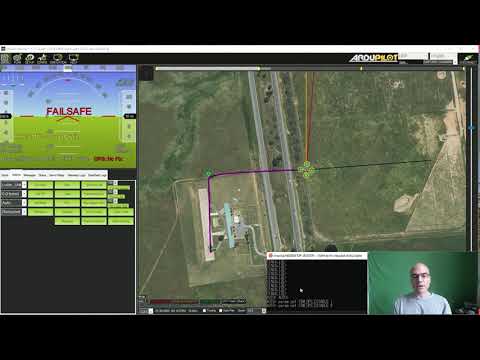
The ATTITUDE_TIME mission command allow the vehicle to autonomous fly at a specified attitude for a given number of seconds within a mission.
WARNING: the "ClimbRate" field of this new command should be left at zero (0) until this MP issue is resolved github.com/ArduPilot/MissionPlanner/issues/2871
This could be used to allow the vehicle to float with the wind for a few seconds or perhaps fly under a bridge where GPS reception might be temporarily interrrupted (because it is attitude control only it does not require a GPS)
The ATTITUDE_TIME mission command allow the vehicle to autonomous fly at a specified attitude for a given number of seconds within a mission.
WARNING: the "ClimbRate" field of this new command should be left at zero (0) until this MP issue is resolved github.com/ArduPilot/MissionPlanner/issues/2871
This could be used to allow the vehicle to float with the wind for a few seconds or perhaps fly under a bridge where GPS reception might be temporarily interrrupted (because it is attitude control only it does not require a GPS)