Uploaded February 2020 | Updated September 2026, 1 week ago
A demonstration of ArduPilot Copter's failover from GPS to Opticalflow.
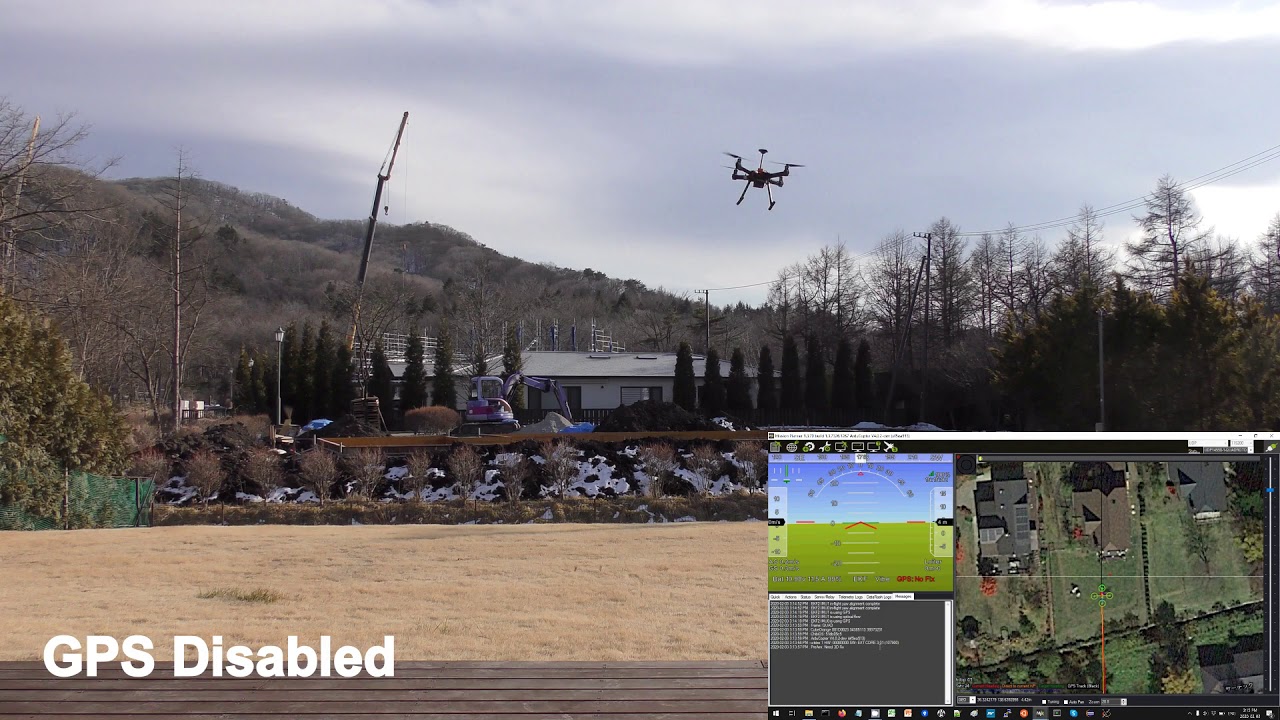
The first half of the video shows the default behaviour with no Optical Flow. Once the GPS is disabled (using an auxiliary switch) the vehicle can only hold position for less than 10seconds before the EKF failsafe triggers a Pilot controlled Land (the pilot controls roll and pitch angles as the vehicle descends)
The second half of the video shows that with an Optical Flow sensor the vehicle can continue to hold position very well even without a GPS.
Please note that it was a fairly windy day so the vehicle is struggling quite a lot to maintain position.
The vehicle is a Hexsoon EDU450 with a Hex CubeOrange autopilot running ArduPilot Copter-4.1-dev. A HereFlow optical flow sensor and Lightware LW20 lidar are used.
A demonstration of ArduPilot Copter's failover from GPS to Opticalflow.
The first half of the video shows the default behaviour with no Optical Flow. Once the GPS is disabled (using an auxiliary switch) the vehicle can only hold position for less than 10seconds before the EKF failsafe triggers a Pilot controlled Land (the pilot controls roll and pitch angles as the vehicle descends)
The second half of the video shows that with an Optical Flow sensor the vehicle can continue to hold position very well even without a GPS.
Please note that it was a fairly windy day so the vehicle is struggling quite a lot to maintain position.
The vehicle is a Hexsoon EDU450 with a Hex CubeOrange autopilot running ArduPilot Copter-4.1-dev. A HereFlow optical flow sensor and Lightware LW20 lidar are used.