Uploaded July 2017 | Updated September 2026, 1 week ago
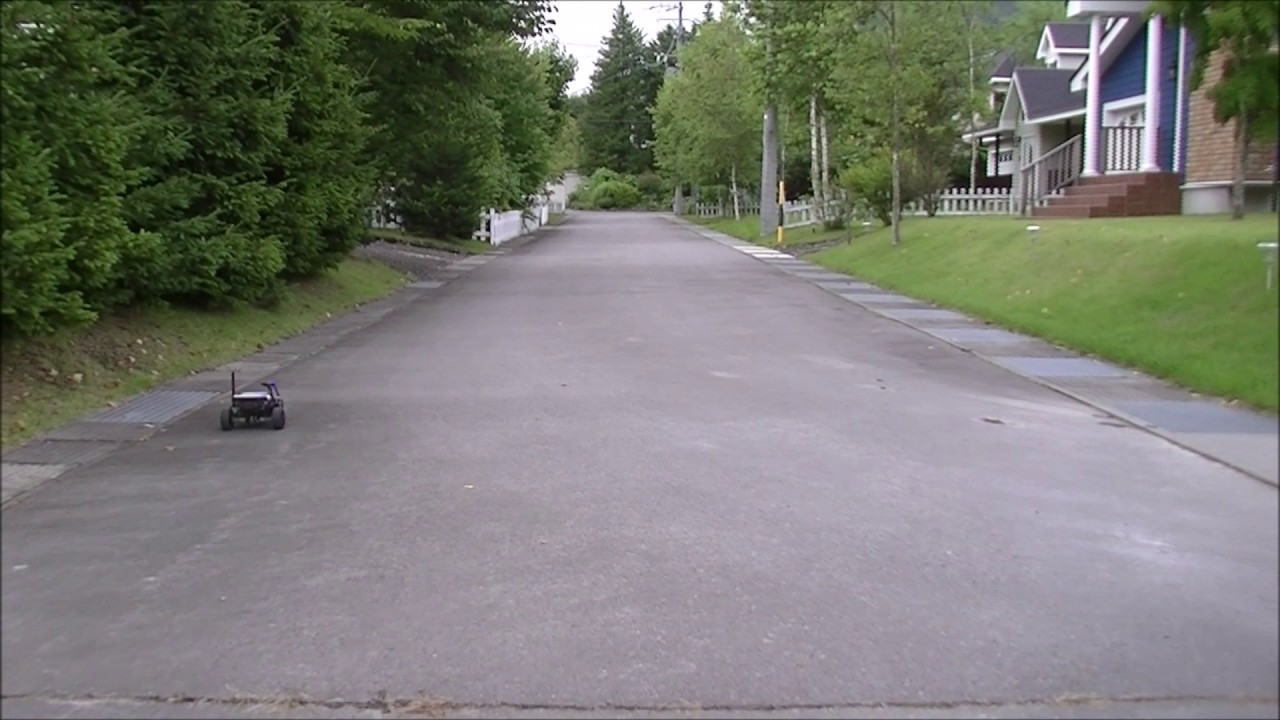
First outdoor test of ArduPilot Rover using brushed motors with built-in wheel encoders to estimate position without using GPS. In this test a simple mission was done consisting of just a single waypoint followed by a Return-To-Launch command
First outdoor test of ArduPilot Rover using brushed motors with built-in wheel encoders to estimate position without using GPS. In this test a simple mission was done consisting of just a single waypoint followed by a Return-To-Launch command