Uploaded October 2015 | Updated September 2026, 1 week ago
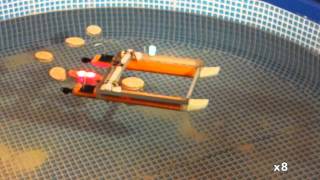
The Year of CoCoRo 41/52: In previous videos we have already demonstrated the ability of a swarm of Jeff robots to find a magnetic target. Now we offer the swarm two different targets of different quality, e.g. because the targets are of different size. In addition to target search we also implemented an improved version of the "fireslime" algorithm, which is inspired by fireflies and slime mould. We have already shown that this algorithm is capable to measure the sizes of local robot groups with just a 1-bit blinking signal. By combining both algorithms of target search and of swarm-size measurement we now can generate a meta-cognition algorithm for the swarm: First the robots search and aggregate at the targets. Then they count the size of their local aggregations and if this number is too low, each robot knows that the swarm, as a whole, did not make a clear decision. This is clear meta-cognition of the swarm: The swarm collectively knows whether or not it knows what the best magnetic target site is.
The Year of CoCoRo 41/52: In previous videos we have already demonstrated the ability of a swarm of Jeff robots to find a magnetic target. Now we offer the swarm two different targets of different quality, e.g. because the targets are of different size. In addition to target search we also implemented an improved version of the "fireslime" algorithm, which is inspired by fireflies and slime mould. We have already shown that this algorithm is capable to measure the sizes of local robot groups with just a 1-bit blinking signal. By combining both algorithms of target search and of swarm-size measurement we now can generate a meta-cognition algorithm for the swarm: First the robots search and aggregate at the targets. Then they count the size of their local aggregations and if this number is too low, each robot knows that the swarm, as a whole, did not make a clear decision. This is clear meta-cognition of the swarm: The swarm collectively knows whether or not it knows what the best magnetic target site is.