Uploaded May 2015 | Updated September 2026, 1 week ago
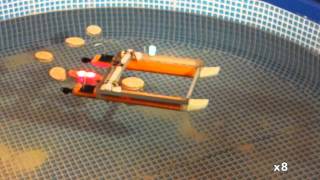
The Year of CoCoRo 21/52: After successful tests of autonomous docking in our pool, we tested this functionality also in Livorno harbor. Despite all the waves, turbulences, wind, rain and other challenges the docking worked very reliable and fast. We could also use the docking to deploy a robot to specific sites with our radio-controlled surface station. Keep in mind: the docking and undocking is autonomous, as is also the Jeff robot as soon as it undocks from the base station.
The Year of CoCoRo 21/52: After successful tests of autonomous docking in our pool, we tested this functionality also in Livorno harbor. Despite all the waves, turbulences, wind, rain and other challenges the docking worked very reliable and fast. We could also use the docking to deploy a robot to specific sites with our radio-controlled surface station. Keep in mind: the docking and undocking is autonomous, as is also the Jeff robot as soon as it undocks from the base station.