Uploaded January 2013 | Updated September 2026, 1 week ago
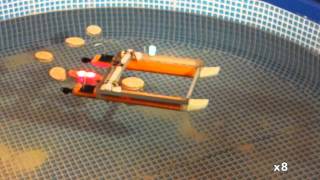
This video shows 5 test runs of an early generation of an evolved shoaling algorithm Each test runs lasts for 500 time-steps, then the AUVs are reset at the starting point. At this state the evolved algorithm is only sometimes capable of keeping the AUVs coherent.
Later generations of the evolving algorithm can be seen here:
Gen436: youtube.com/watch?v=IGgnhgpDyyQ
Gen750: youtube.com/watch?v=poRepPCvH70
Alternative EA run Gen600: youtube.com/watch?v=puaWyS041rQ
The evolvable parameters allowed the AUVs to change their perception and also their reaction to other near AUVs.
This video shows 5 test runs of an early generation of an evolved shoaling algorithm Each test runs lasts for 500 time-steps, then the AUVs are reset at the starting point. At this state the evolved algorithm is only sometimes capable of keeping the AUVs coherent.
Later generations of the evolving algorithm can be seen here:
Gen436: youtube.com/watch?v=IGgnhgpDyyQ
Gen750: youtube.com/watch?v=poRepPCvH70
Alternative EA run Gen600: youtube.com/watch?v=puaWyS041rQ
The evolvable parameters allowed the AUVs to change their perception and also their reaction to other near AUVs.