Uploaded April 2015 | Updated September 2026, 1 week ago
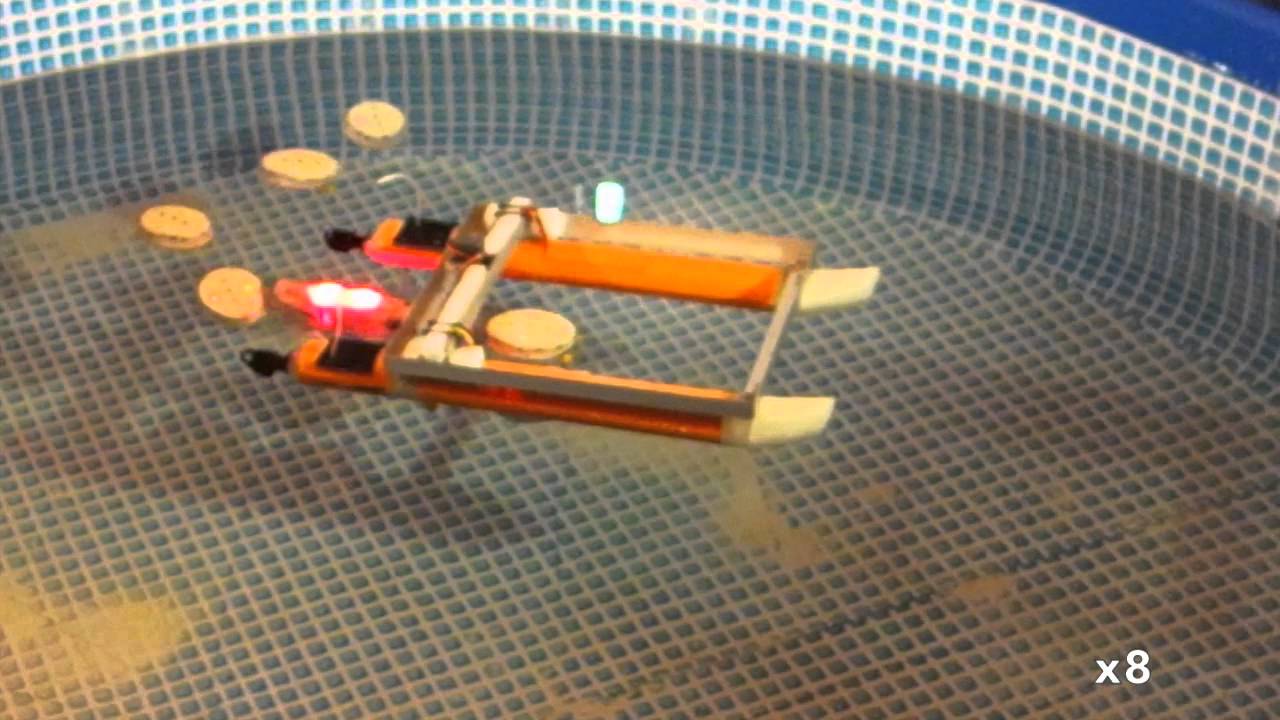
The Year of CoCoRo 17/52: In this video we use blue-light blinks to keep the swarm together and to keep it in vicinity of the moving base station. Due to this „confinement“, the radio-controlled base-station can pull a whole swarm of Lily robots like a tail behind itself. It is important to confine the robots into specific areas in larger water bodies because the swarm requires normally a minimum connectivity among agents to work efficiently, which is achieved only with a critical minimum swarm density. Without keeping the robots in a controlled area, robots could get lost and the robot density could fall below the critical density. Thus, confinement was identified to be a critical functionality.
The Year of CoCoRo 17/52: In this video we use blue-light blinks to keep the swarm together and to keep it in vicinity of the moving base station. Due to this „confinement“, the radio-controlled base-station can pull a whole swarm of Lily robots like a tail behind itself. It is important to confine the robots into specific areas in larger water bodies because the swarm requires normally a minimum connectivity among agents to work efficiently, which is achieved only with a critical minimum swarm density. Without keeping the robots in a controlled area, robots could get lost and the robot density could fall below the critical density. Thus, confinement was identified to be a critical functionality.