Uploaded June 2015 | Updated September 2026, 1 week ago
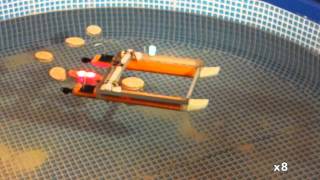
The Year of CoCoRo 26/52: We constructed a fragmented habitat in a pool providing 4 compartments separated by medium-height walls. One compartment contained a magnetic/metallic object acting as a search target. One JEFF robot was introduced performing a random-walk-based search pattern occasionally interrupted by a "jump-over-the-wall" behavior to allow it to switch compartment after a collision event by blue-light LEDs was detected. The autonomous robot observed its internal magnetic sensor to identify the target in case it is nearby. In this case, it stops there, sinks on top of the target and switches on its LEDs to mark it. The video shows a series of experiments to see how many successful results we can achieve in a row and how often "false positives" happen. We were quite surprised about the reliability of the behavior given the fact that the robot is only driving randomly (no specific optimized search pattern!) and no higher-cognitive capabilities (no map, no camera, no memory, no plan!) are involved.
The Year of CoCoRo 26/52: We constructed a fragmented habitat in a pool providing 4 compartments separated by medium-height walls. One compartment contained a magnetic/metallic object acting as a search target. One JEFF robot was introduced performing a random-walk-based search pattern occasionally interrupted by a "jump-over-the-wall" behavior to allow it to switch compartment after a collision event by blue-light LEDs was detected. The autonomous robot observed its internal magnetic sensor to identify the target in case it is nearby. In this case, it stops there, sinks on top of the target and switches on its LEDs to mark it. The video shows a series of experiments to see how many successful results we can achieve in a row and how often "false positives" happen. We were quite surprised about the reliability of the behavior given the fact that the robot is only driving randomly (no specific optimized search pattern!) and no higher-cognitive capabilities (no map, no camera, no memory, no plan!) are involved.