Uploaded October 2017 | Updated September 2026, 1 week ago
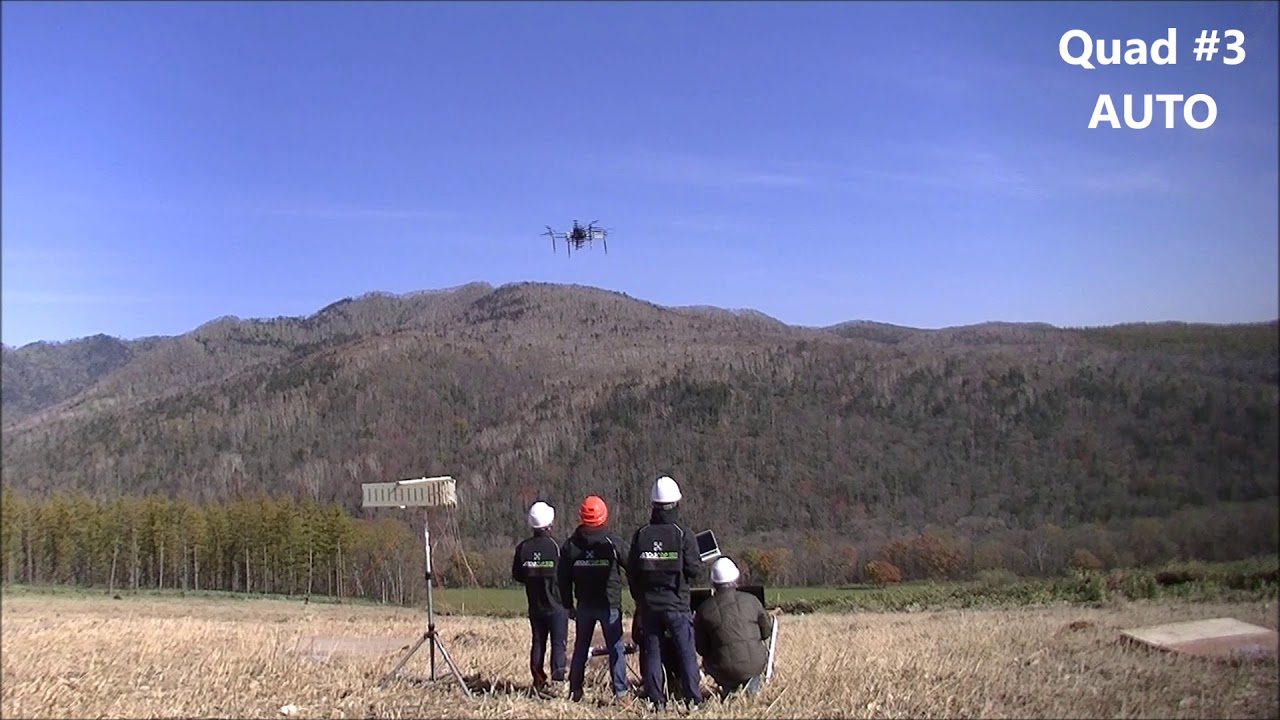
TAP-J (Team ArduPilot Japan) on day 4 of the Japan Innovation Challenge 2017. We successfully found a dummy hidden in the forest using Four eLAB 470 quadcopters with Pixhawk Cube 2.1 autopilots running ArduPilot Copter 3.5.3. RPI3 companion computers with UCTronics 8MP ArduCam cameras. Tarot gimbal.
Final image processing was done using CUAV, Canberra UAV's open source image processing software originally developed for Australia's Outback Challenge
TAP-J (Team ArduPilot Japan) on day 4 of the Japan Innovation Challenge 2017. We successfully found a dummy hidden in the forest using Four eLAB 470 quadcopters with Pixhawk Cube 2.1 autopilots running ArduPilot Copter 3.5.3. RPI3 companion computers with UCTronics 8MP ArduCam cameras. Tarot gimbal.
Final image processing was done using CUAV, Canberra UAV's open source image processing software originally developed for Australia's Outback Challenge