Uploaded December 2015 | Updated September 2026, 1 week ago
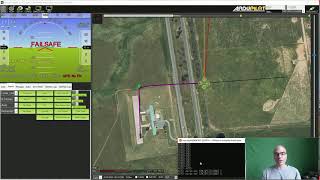
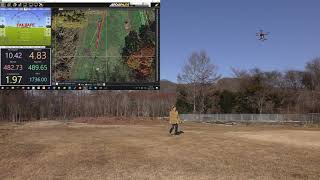
Test of Qualcomm Snapdragon running APM:Copter-3.4-dev on IRIS+ doing a short spline mission around the neighbourhood.
wiki: copter.ardupilot.com/wiki/common-qualcomm-snapdragon-flight-kit
Live video from the vehicle was accomplished using "qcamvid" on the flight controller and VLC media player on the windows laptop.
The telemetry connection to Mission Planner and Tower were using UDP over wifi.
A regular RC transmitter was available for emergencies but the flight was performed completely using Tower.
Test of Qualcomm Snapdragon running APM:Copter-3.4-dev on IRIS+ doing a short spline mission around the neighbourhood.
wiki: copter.ardupilot.com/wiki/common-qualcomm-snapdragon-flight-kit
Live video from the vehicle was accomplished using "qcamvid" on the flight controller and VLC media player on the windows laptop.
The telemetry connection to Mission Planner and Tower were using UDP over wifi.
A regular RC transmitter was available for emergencies but the flight was performed completely using Tower.