Uploaded September 2022 | Updated September 2026, 3 weeks ago
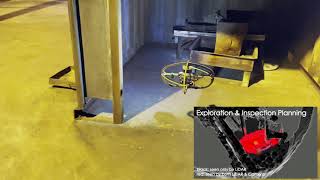
This work contributes a novel strategy for semantics-aware autonomous exploration and inspection path planning. Attuned to the fact that environments that need to be explored often involve a sparse set of semantic entities of particular interest, the proposed method offers volumetric exploration combined with two new planning behaviors that together ensure that a complete mesh model is reconstructed for each semantic, while its surfaces are observed at appropriate resolution and through suitable viewing angles. Evaluated in extensive simulation studies and experimental results using a flying robot, the planner delivers efficient combined exploration and high-fidelity inspection planning that is focused on the semantics of interest. Comparisons against relevant methods of the state-of-the-art are further presented.
This work contributes a novel strategy for semantics-aware autonomous exploration and inspection path planning. Attuned to the fact that environments that need to be explored often involve a sparse set of semantic entities of particular interest, the proposed method offers volumetric exploration combined with two new planning behaviors that together ensure that a complete mesh model is reconstructed for each semantic, while its surfaces are observed at appropriate resolution and through suitable viewing angles. Evaluated in extensive simulation studies and experimental results using a flying robot, the planner delivers efficient combined exploration and high-fidelity inspection planning that is focused on the semantics of interest. Comparisons against relevant methods of the state-of-the-art are further presented.