Uploaded July 2022 | Updated September 2026, 3 weeks ago
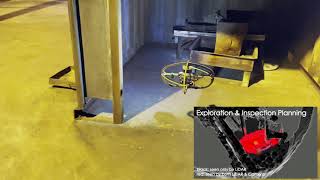
In this experiment, we demonstrate a combined exploration and inspection mission using the RMF-Owl collision tolerant aerial robot inside the Nutec RelyOn facilities in Trondheim, Norway. The robot is tasked to autonomously explore and inspect the surfaces of the environment - within a height boundary - with its onboard camera sensor given no prior knowledge of the map.
To accomplish its task, the system utilizes a modified version of our open-sourced Graph-Based Exploration Path Planner. The planner utilizes voxblox as the volumetric mapping framework for planning and periodically annotates the mapped voxels lying inside the camera frustum, while a depth sensor is used for volumetric exploration. The planner then calculates a path that maximizes the umount of unseen surface that will be seen by the camera.
The work is part of our ongoing efforts for optimized exploration and inspection path planning inside vessel ballast and cargo tanks, as well as industrial process and storage tanks.
In this experiment, we demonstrate a combined exploration and inspection mission using the RMF-Owl collision tolerant aerial robot inside the Nutec RelyOn facilities in Trondheim, Norway. The robot is tasked to autonomously explore and inspect the surfaces of the environment - within a height boundary - with its onboard camera sensor given no prior knowledge of the map.
To accomplish its task, the system utilizes a modified version of our open-sourced Graph-Based Exploration Path Planner. The planner utilizes voxblox as the volumetric mapping framework for planning and periodically annotates the mapped voxels lying inside the camera frustum, while a depth sensor is used for volumetric exploration. The planner then calculates a path that maximizes the umount of unseen surface that will be seen by the camera.
The work is part of our ongoing efforts for optimized exploration and inspection path planning inside vessel ballast and cargo tanks, as well as industrial process and storage tanks.