Uploaded August 2020 | Updated November 2026, 12 hours ago
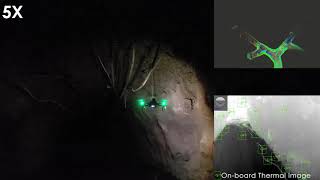
Resilient pose estimation for autonomous systems, and especially small unmanned aerial robots, is one of the core capabilities required for these robots to perform their assigned tasks in a reliable and efficient manner. Different sensing modalities have been utilized for the robot pose estimation process, particularly in GPS-denied environments. However, as aerial robots are deployed in more complex environments, such as subterranean mines and tunnels, different sensing modalities can become degraded in different parts of the environment due to the diversity of sensor perception challenges presented in terms of both nature and condition of the operational environment. Motivated by this fact, in this work a complementary multi-modal sensor fusion approach is presented that improves the reliability of the pose estimation process for aerial robots by fusing visual-inertial (VIO) and thermal-inertial (TIO) odometry estimates with a LiDAR odometry and mapping solution. In particular, VIO/TIO estimates are utilized for providing robust priors for LiDAR pose estimation as well as for selectively propagating the LiDAR pose estimates when LiDAR pose estimation process becomes degenerate. The proposed approach is experimentally verified in a variety of subterranean environments as well as utilized during the competition run of the tunnel circuit of the DARPA Subterranean Challenge.
Resilient pose estimation for autonomous systems, and especially small unmanned aerial robots, is one of the core capabilities required for these robots to perform their assigned tasks in a reliable and efficient manner. Different sensing modalities have been utilized for the robot pose estimation process, particularly in GPS-denied environments. However, as aerial robots are deployed in more complex environments, such as subterranean mines and tunnels, different sensing modalities can become degraded in different parts of the environment due to the diversity of sensor perception challenges presented in terms of both nature and condition of the operational environment. Motivated by this fact, in this work a complementary multi-modal sensor fusion approach is presented that improves the reliability of the pose estimation process for aerial robots by fusing visual-inertial (VIO) and thermal-inertial (TIO) odometry estimates with a LiDAR odometry and mapping solution. In particular, VIO/TIO estimates are utilized for providing robust priors for LiDAR pose estimation as well as for selectively propagating the LiDAR pose estimates when LiDAR pose estimation process becomes degenerate. The proposed approach is experimentally verified in a variety of subterranean environments as well as utilized during the competition run of the tunnel circuit of the DARPA Subterranean Challenge.