Uploaded January 2021 | Updated September 2026, 3 weeks ago
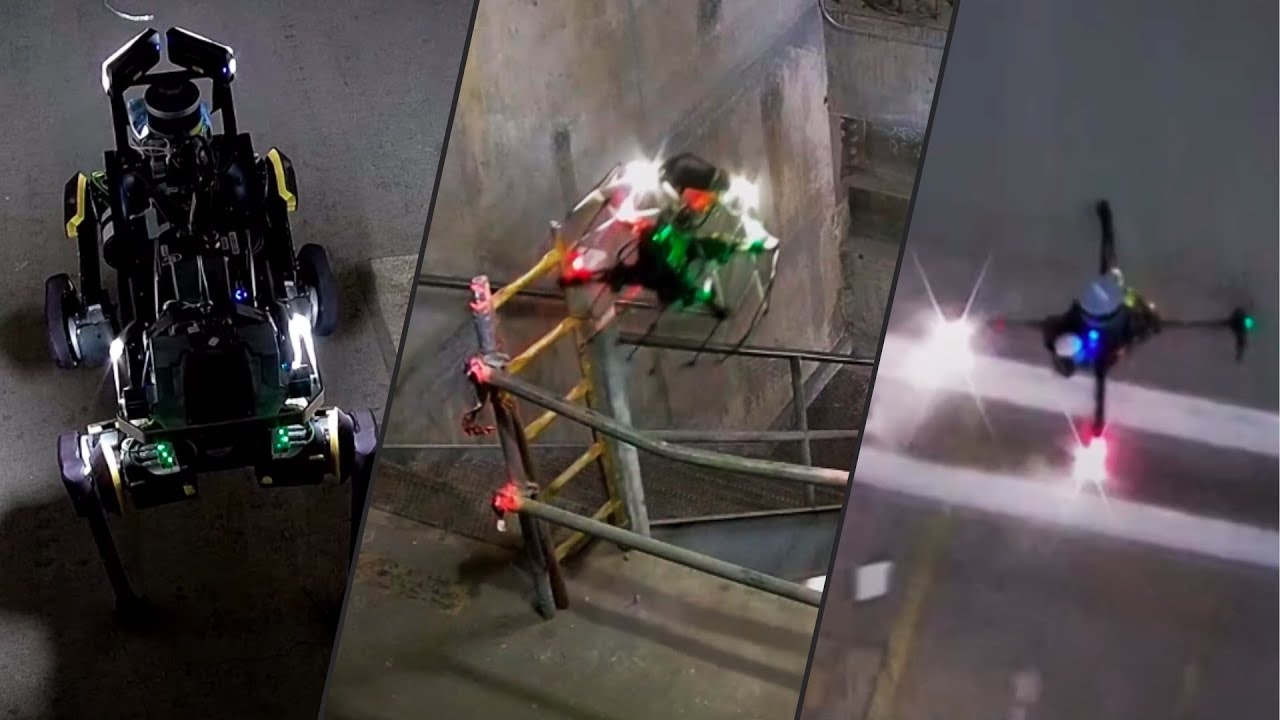
This paper reports the technological progress and performance of team “CERBERUS” after participating in the Tunnel and Urban Circuits of the DARPA Subterranean Challenge. The SubT Challenge is an international robotics competition organized by the Defense Advanced Research Projects Agency to inspire advances in resilient robotic autonomy in subterranean settings. Teams compete to explore, map, and search a completely unknown environment including tunnels, mines, caves, and urban subterranean infrastructure.Each team receives a 60 minute time slot to find various objects of interest, called artifacts, in an underground setting. For each artifact found and correctly localized, the team earns a point.Finally, and critically, only a single human supervisor may communicate with the robots once they are deployed. Motivated by and responding to these challenges, the CERBERUS collaborative walking and flying robotic system-of-systems envisions the autonomous exploration of such subterranean environments through the synergistic operation of diverse systems with unique navigation capabilities. The principal idea behind CERBERUS' vision is that the combination of legged and aerial systems offers unique advantages tailored to the needs of complex underground settings. Walking robots present potential benefits for overcoming complex terrain, both in terms of the size of obstacles that can be negotiated for a certain overall robot size, and the robust traversal of dynamic terrain. Aerial robots, especially when equipped with collision-tolerance capabilities, offer the advantage of seamless navigation that is not bound to the extreme terrain challenges often present in environments such as caves. CERBERUS focuses on the co-deployment of such legged and aerial robots further equipped with resilient multi-modal and multi-robot localization and mapping, artifact detection and universal exploration path planning capabilities. A robot-deployable communications network solution is being realized which allows the CERBERUS robotic system to deploy its own communications network underground. The results presented in this paper outline the experience of the Tunnel and Urban Circuit, the first relating to the exploration of the underground NIOSH Mining Program’s Safety Research and Experimental Mines and the second, an unfinished nuclear facility at the Satsop Business Park in Elma, Washington.
Team CERBERUS is an international partnership involving the following members:
* Autonomous Robots Lab, University of Nevada, Reno & Norwegian University of Science and Technology
* Robotic Systems Lab, ETH Zurich
* Autonomous Systems Lab, ETH Zurich
* HiPeR Lab, University of California, Berkeley
* Dynamic Robot Systems Group, University of Oxford
* Flyability
* Sierra Nevada Corporation
This paper reports the technological progress and performance of team “CERBERUS” after participating in the Tunnel and Urban Circuits of the DARPA Subterranean Challenge. The SubT Challenge is an international robotics competition organized by the Defense Advanced Research Projects Agency to inspire advances in resilient robotic autonomy in subterranean settings. Teams compete to explore, map, and search a completely unknown environment including tunnels, mines, caves, and urban subterranean infrastructure.Each team receives a 60 minute time slot to find various objects of interest, called artifacts, in an underground setting. For each artifact found and correctly localized, the team earns a point.Finally, and critically, only a single human supervisor may communicate with the robots once they are deployed. Motivated by and responding to these challenges, the CERBERUS collaborative walking and flying robotic system-of-systems envisions the autonomous exploration of such subterranean environments through the synergistic operation of diverse systems with unique navigation capabilities. The principal idea behind CERBERUS' vision is that the combination of legged and aerial systems offers unique advantages tailored to the needs of complex underground settings. Walking robots present potential benefits for overcoming complex terrain, both in terms of the size of obstacles that can be negotiated for a certain overall robot size, and the robust traversal of dynamic terrain. Aerial robots, especially when equipped with collision-tolerance capabilities, offer the advantage of seamless navigation that is not bound to the extreme terrain challenges often present in environments such as caves. CERBERUS focuses on the co-deployment of such legged and aerial robots further equipped with resilient multi-modal and multi-robot localization and mapping, artifact detection and universal exploration path planning capabilities. A robot-deployable communications network solution is being realized which allows the CERBERUS robotic system to deploy its own communications network underground. The results presented in this paper outline the experience of the Tunnel and Urban Circuit, the first relating to the exploration of the underground NIOSH Mining Program’s Safety Research and Experimental Mines and the second, an unfinished nuclear facility at the Satsop Business Park in Elma, Washington.
Team CERBERUS is an international partnership involving the following members:
* Autonomous Robots Lab, University of Nevada, Reno & Norwegian University of Science and Technology
* Robotic Systems Lab, ETH Zurich
* Autonomous Systems Lab, ETH Zurich
* HiPeR Lab, University of California, Berkeley
* Dynamic Robot Systems Group, University of Oxford
* Flyability
* Sierra Nevada Corporation


