Uploaded May 2026 | Updated September 2026, 3 weeks ago
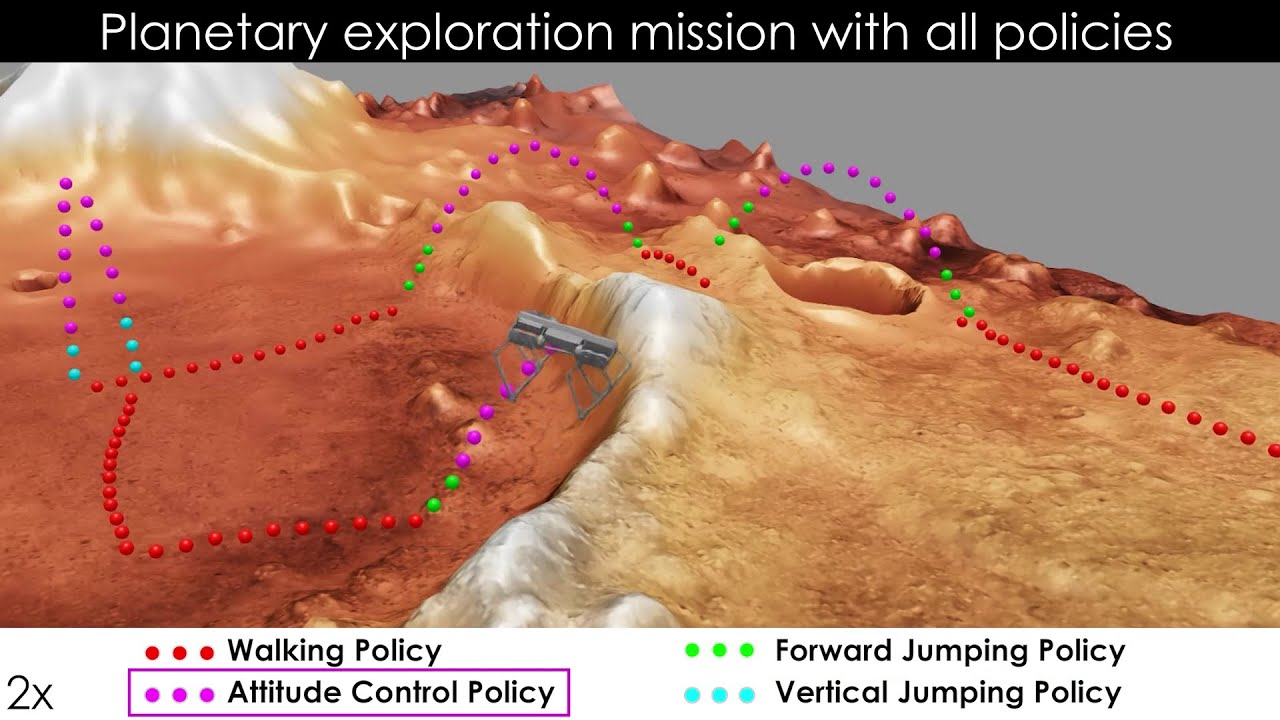
This work presents reinforcement learning (RL) policies for dynamic quadrupedal locomotion in planetary exploration scenarios. Building on a task-optimized quadruped with a 5-bar leg design, we develop RL policies for walking, vertical jumping, forward jumping, and in-flight attitude control, explicitly tailored for the reduced gravity on Mars. These policies jointly enable such robots to overcome obstacles larger than themselves through coordinated jumping and precise in-flight reorientation for safe landings. We demonstrate Sim2Real transfer of the attitude control policy on the Olympus quadruped through single-axis reorientation tests, while all locomotion policies are validated in simulation. A complete Mars exploration mission scenario demonstrates coordinated policy deployment across challenging terrain. Experimental results show 90 degrees attitude reorientation in 2.5 seconds, with simulations demonstrating 3.1 meter vertical jumps and 3.9 meter forward jumps under Martian gravity conditions.
This work presents reinforcement learning (RL) policies for dynamic quadrupedal locomotion in planetary exploration scenarios. Building on a task-optimized quadruped with a 5-bar leg design, we develop RL policies for walking, vertical jumping, forward jumping, and in-flight attitude control, explicitly tailored for the reduced gravity on Mars. These policies jointly enable such robots to overcome obstacles larger than themselves through coordinated jumping and precise in-flight reorientation for safe landings. We demonstrate Sim2Real transfer of the attitude control policy on the Olympus quadruped through single-axis reorientation tests, while all locomotion policies are validated in simulation. A complete Mars exploration mission scenario demonstrates coordinated policy deployment across challenging terrain. Experimental results show 90 degrees attitude reorientation in 2.5 seconds, with simulations demonstrating 3.1 meter vertical jumps and 3.9 meter forward jumps under Martian gravity conditions.


