Uploaded May 2026 | Updated November 2026, 1 hour ago
Open-Source Code: github.com/ntnu-arl/unified_autonomy_stack
Paper: arxiv.org/abs/2605.12735
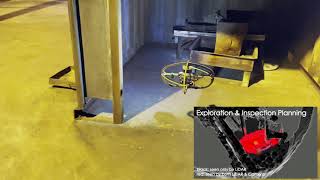
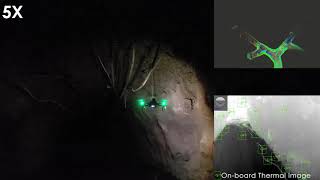
We introduce and open-source the Unified Autonomy Stack, a system-level solution that enables resilient autonomy across diverse aerial and ground robot morphologies. The architecture centers on three synergistic modules - multi-modal perception, multi-behavior planning, and multi-layered safe navigation - that together deliver comprehensive mission autonomy. The stack fuses data from LiDAR, radar, vision, and inertial sensing, enabling (a) robust tightly-coupled localization and mapping through factor graph-based fusion, (b) semantic scene understanding, (c) motion and informative path planning through sampling-based techniques adaptive across spatial scales, as well as (d) multi-layered safe navigation both through planning on the online reconstructed map and deep learning-driven exteroceptive policies alongside last-resort safety filters using control barrier functions. The resulting behaviors include safe GNSS-denied navigation into unknown and perceptually-degraded regions, exploration of complex environments, object discovery, and efficient inspection planning. The stack has been field-tested and validated on both aerial (rotorcraft) and ground (legged) robots operating in a host of demanding environments, including self-similar and smoke-filled settings, with complex geometries and high obstacle clutter. These tests demonstrate resilient performance in challenging conditions. To facilitate ease of adoption, we open-source the implementation alongside supporting documentation, validation, and evaluation datasets.
Open-Source Code: github.com/ntnu-arl/unified_autonomy_stack
Paper: arxiv.org/abs/2605.12735
We introduce and open-source the Unified Autonomy Stack, a system-level solution that enables resilient autonomy across diverse aerial and ground robot morphologies. The architecture centers on three synergistic modules - multi-modal perception, multi-behavior planning, and multi-layered safe navigation - that together deliver comprehensive mission autonomy. The stack fuses data from LiDAR, radar, vision, and inertial sensing, enabling (a) robust tightly-coupled localization and mapping through factor graph-based fusion, (b) semantic scene understanding, (c) motion and informative path planning through sampling-based techniques adaptive across spatial scales, as well as (d) multi-layered safe navigation both through planning on the online reconstructed map and deep learning-driven exteroceptive policies alongside last-resort safety filters using control barrier functions. The resulting behaviors include safe GNSS-denied navigation into unknown and perceptually-degraded regions, exploration of complex environments, object discovery, and efficient inspection planning. The stack has been field-tested and validated on both aerial (rotorcraft) and ground (legged) robots operating in a host of demanding environments, including self-similar and smoke-filled settings, with complex geometries and high obstacle clutter. These tests demonstrate resilient performance in challenging conditions. To facilitate ease of adoption, we open-source the implementation alongside supporting documentation, validation, and evaluation datasets.