Uploaded February 2021 | Updated September 2026, 1 hour ago
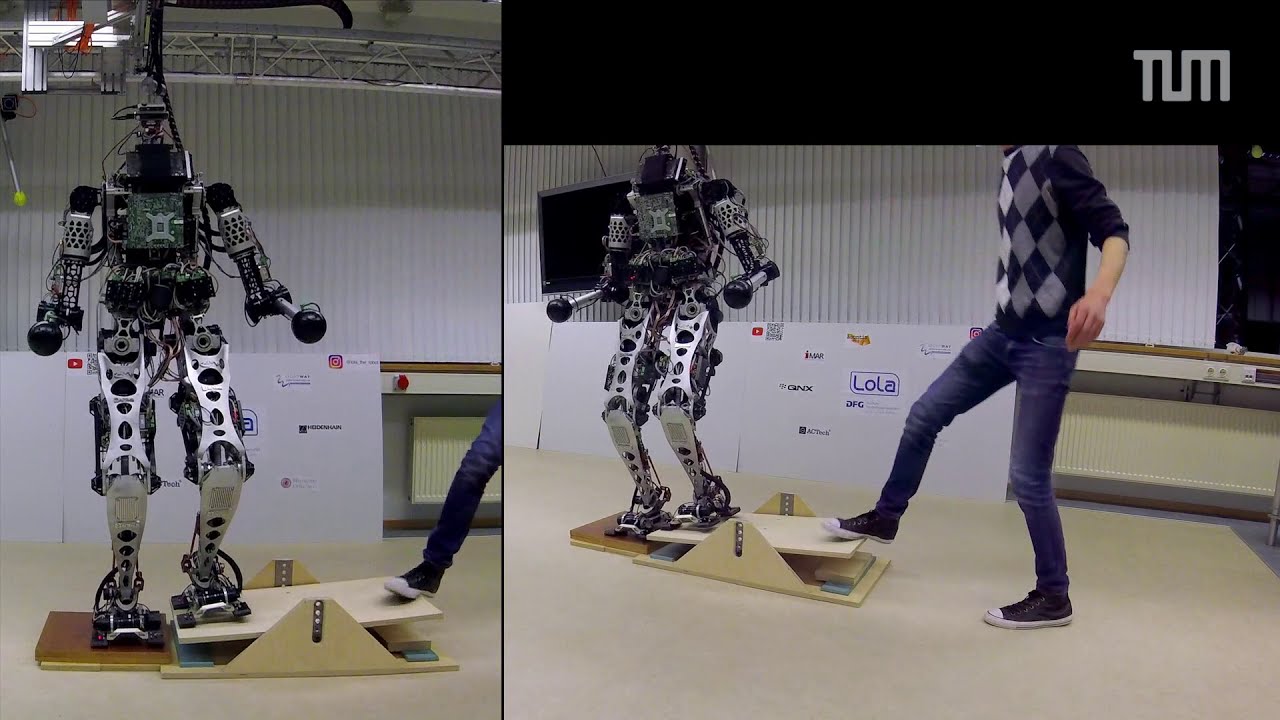
In this video, LOLA reacts to undetected ground height changes, including a drop and leg-in-hole experiment. Further tests show the robustness to vertical disturbances using a seesaw. The robot is technically blind, not using any camera-based or prior information on the terrain.
Technical Details:
Walking speed: 0.5 m/s
Height of the board: 6.7cm
Ground height change leg-in-hole: 6cm
Negative ground height change platform: 9cm
For more information on LOLA please see our project's website: mw.tum.de/en/am/research/current-projects/robotics/humanoid-robot-lola
This work is supported by the German Research Foundation (DFG, project number 407378162).
In this video, LOLA reacts to undetected ground height changes, including a drop and leg-in-hole experiment. Further tests show the robustness to vertical disturbances using a seesaw. The robot is technically blind, not using any camera-based or prior information on the terrain.
Technical Details:
Walking speed: 0.5 m/s
Height of the board: 6.7cm
Ground height change leg-in-hole: 6cm
Negative ground height change platform: 9cm
For more information on LOLA please see our project's website: mw.tum.de/en/am/research/current-projects/robotics/humanoid-robot-lola
This work is supported by the German Research Foundation (DFG, project number 407378162).