Uploaded March 2015 | Updated September 2026, 2 hours ago
In this video, our latest modular agricultural manipulator is shown in its 9 DOF redundant configuration picking artificial sweet-pepper in our laboratory. The manipulator has been developed within the EU-project CROPS for harvesting sweet-pepper, apples and grapes as well as precision spraying of diseased grapes.
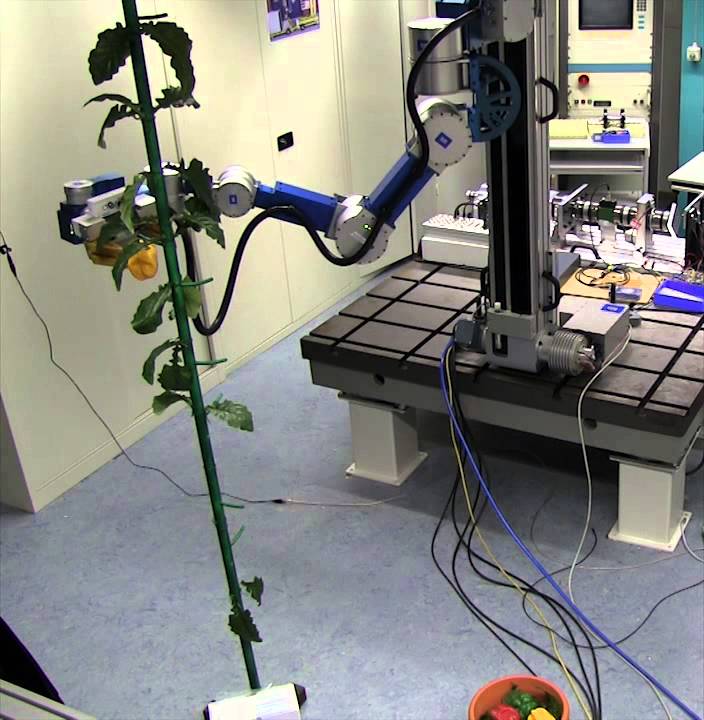
In this video, our latest modular agricultural manipulator is shown in its 9 DOF redundant configuration picking artificial sweet-pepper in our laboratory. The manipulator has been developed within the EU-project CROPS for harvesting sweet-pepper, apples and grapes as well as precision spraying of diseased grapes.