Uploaded December 2020 | Updated September 2026, 1 hour ago
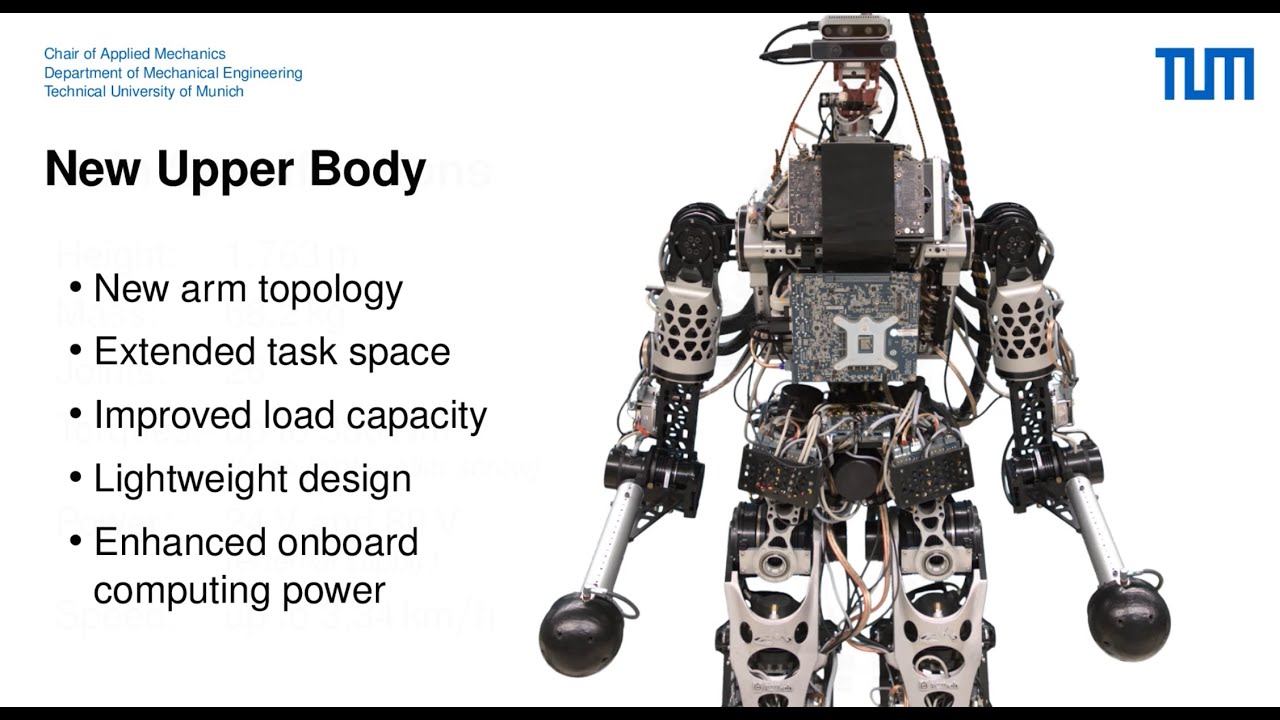
In this video we present initial tests of our humanoid robot LOLA, which has recently received a major hardware upgrade. In particular the upper body of the robot was redesigned from scratch. The video is meant to demonstrate its basic operation. Note that this is raw footage of initial tests, i.e., WITHOUT fine-tuning of control parameters.
Balancing:
The robot is standing in an idle pose and receives external forces. The controller is able to compensate the disturbances without exciting oscillations.
Stamping:
The robot is commanded to walk in place, i.e., straight walking with a step length of zero. This kind of motion is typically more difficult for our robot when compared to "normal" walking.
Walking:
Basic straight walking of a fixed step sequence.
For more information please see our project's website: mw.tum.de/en/am/research/current-projects/robotics/humanoid-robot-lola
This work is supported by the German Research Foundation (DFG, project number 407378162).
In this video we present initial tests of our humanoid robot LOLA, which has recently received a major hardware upgrade. In particular the upper body of the robot was redesigned from scratch. The video is meant to demonstrate its basic operation. Note that this is raw footage of initial tests, i.e., WITHOUT fine-tuning of control parameters.
Balancing:
The robot is standing in an idle pose and receives external forces. The controller is able to compensate the disturbances without exciting oscillations.
Stamping:
The robot is commanded to walk in place, i.e., straight walking with a step length of zero. This kind of motion is typically more difficult for our robot when compared to "normal" walking.
Walking:
Basic straight walking of a fixed step sequence.
For more information please see our project's website: mw.tum.de/en/am/research/current-projects/robotics/humanoid-robot-lola
This work is supported by the German Research Foundation (DFG, project number 407378162).