Uploaded March 2021 | Updated September 2026, 3 hours ago
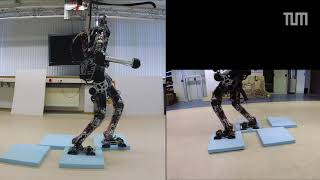
In this video, LOLA reacts to randomly arranged, undetected soft and hard obstacles. The robot is technically blind, not using any camera-based or prior information on the terrain (hard ground is assumed). Due to the limited transmission of contact forces, unexpectedly soft obstacles are typically more difficult to overcome. When LOLA steps on soft obstacles, the control adapts itself to achieve similar performance to walking on hard ground.
Technical Details:
All runs use the same parametrization for the walking controller and identical footstep locations.
Walking speed: 0.5 m/s
Height of the foam sheets: 5cm
Density of the foam: 40 kg/m^3
Compression hardness of the foam: 6 kPa @ 40% compression
For more information on LOLA please see our project's website: mw.tum.de/en/am/research/current-projects/robotics/humanoid-robot-lola
This work is supported by the German Research Foundation (DFG, project number 407378162).
In this video, LOLA reacts to randomly arranged, undetected soft and hard obstacles. The robot is technically blind, not using any camera-based or prior information on the terrain (hard ground is assumed). Due to the limited transmission of contact forces, unexpectedly soft obstacles are typically more difficult to overcome. When LOLA steps on soft obstacles, the control adapts itself to achieve similar performance to walking on hard ground.
Technical Details:
All runs use the same parametrization for the walking controller and identical footstep locations.
Walking speed: 0.5 m/s
Height of the foam sheets: 5cm
Density of the foam: 40 kg/m^3
Compression hardness of the foam: 6 kPa @ 40% compression
For more information on LOLA please see our project's website: mw.tum.de/en/am/research/current-projects/robotics/humanoid-robot-lola
This work is supported by the German Research Foundation (DFG, project number 407378162).