Humanoid Robot JOHNNIE at the Hannover Fair 2003 @AppliedMechanicsTUM
Humanoid Robot JOHNNIE at the Hannover Fair 2003  @AppliedMechanicsTUM
Uploaded March 2015 | Updated September 2026, 14 hours ago
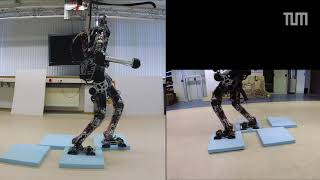
Presentation of two-legged walking robot "Johnnie", with autonomous walking, overcoming of obstacles and walking on stairs. Hannover Messe 2003.
Humanoid Robot JOHNNIE at the Hannover Fair 2003CVT Simulation - Element ForcesCROPS Manipulator (Generation 2) in 9 DOF configuration picking sweet-pepper in labHumanoid Robot LOLA - Robustness to Soft and Hard ObstaclesA Flexible and Low Cost Tactile Sensor for Robotic ApplicationsSix-legged robot MAX first steps - 1994Shape-Memory ActuatorsHumanoid Robot LOLA v1.1 - Validation of Hardware Upgrade - Initial TestsNumerical and Experimental OptimizationCROPS Manipulator (Generation 1) picking sweet-pepper in labALE Beam Model: Full DeformationEuRoC first round (simulation - Challenge 2) AM-Robotics
TUM Chair of Applied Mechanics |

Humanoid Robot JOHNNIE at the Hannover Fair 2003

SHARE TO X SHARE TO REDDIT SHARE TO FACEBOOK WALLPAPER