Uploaded July 2017 | Updated September 2026, 3 hours ago
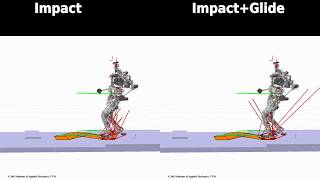
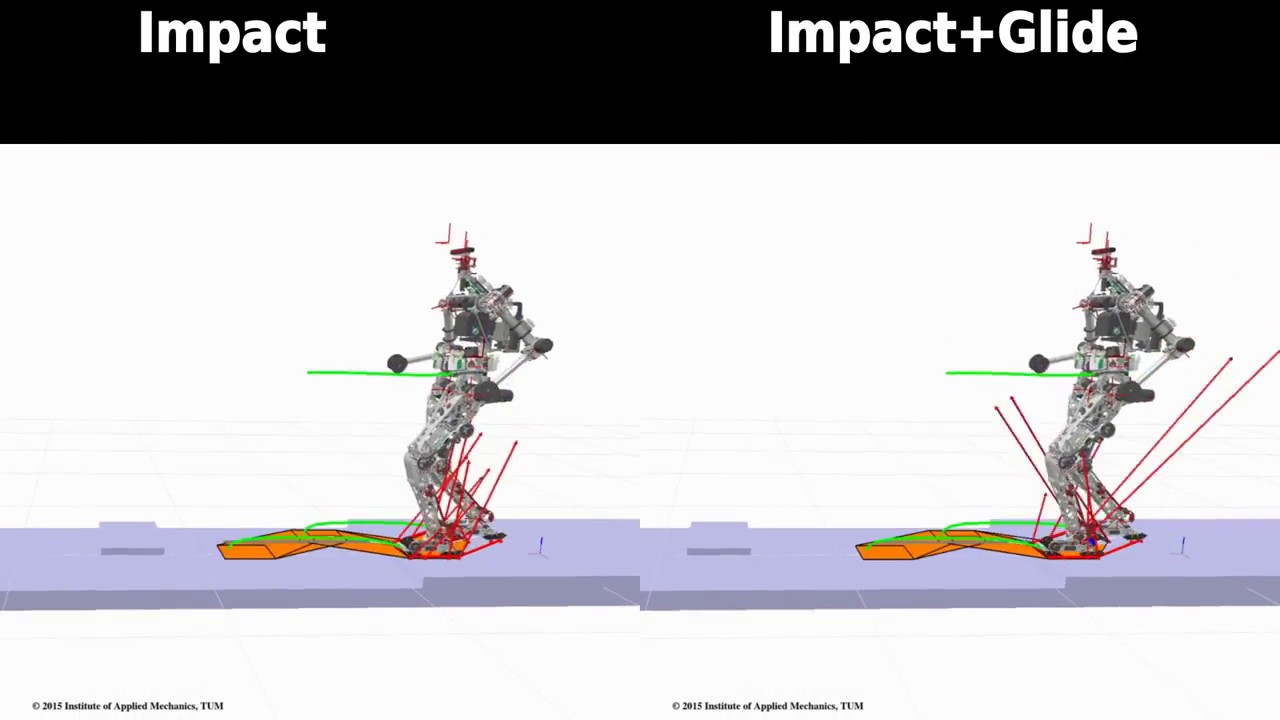
In this video we shortly present our new time-variable, event-based walking control for biped robots. We add two phases to our walking control which are activated when the robot finds itself in an early-contact or late-contact scenario. The newest phase, "glide", specifically deals with a late-contact scenario by preventing the tilting over of the robot. With it, our humanoid lola can deal with leg-in-hole situations. Real experiments coming soon!
Check out our open source repositories!
github.com/am-lola
In this video we shortly present our new time-variable, event-based walking control for biped robots. We add two phases to our walking control which are activated when the robot finds itself in an early-contact or late-contact scenario. The newest phase, "glide", specifically deals with a late-contact scenario by preventing the tilting over of the robot. With it, our humanoid lola can deal with leg-in-hole situations. Real experiments coming soon!
Check out our open source repositories!
github.com/am-lola