Uploaded August 2015 | Updated September 2026, 1 week ago
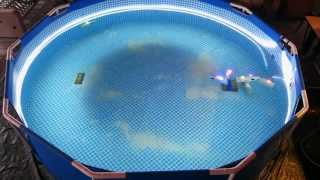
The Year of CoCoRo 33/52: In the CoCoRo system there is often a distant gap between the swarm of Jeff robots on the ground that found a search target and the base station at the water surface. Underwater communication is often difficult and limited. To bridge this gap in communication a swarm of Lily robots build a chain, which we call a "relay chain", as it serves as a relay that allow the ground swarm and the surface station to communicate with each other through light pulses, RF or electric pulses. Here we show several instances of such a relay chain in the middle phase of our "combined scenario #1" and we test information transfer in both directions by triggering either the ground swarm or the base station with a flashlight pulse. The relay chain is formed by Lily robots by executing a special "shoaling algorithm" which is inspired by fish shoaling behavior. It is based on reactions to nearest neighbors sensed passively by photodiodes on the outer hull of the Lily robots. Reception of periodic blue-light blinks allows the robots to detect each other and to align/orient relative to the neighboring configuration. Thus the relay chain formation itself is almost communication-free, as the photodiodes and blinks could be easily replaced by a video camera and object detection. It is just passive sensing and interpretation of the local environment. The only communication act performed is the relaying of the RF pulse information, which was implemented similar to slime-mould amoebas' communication strategy.
The Year of CoCoRo 33/52: In the CoCoRo system there is often a distant gap between the swarm of Jeff robots on the ground that found a search target and the base station at the water surface. Underwater communication is often difficult and limited. To bridge this gap in communication a swarm of Lily robots build a chain, which we call a "relay chain", as it serves as a relay that allow the ground swarm and the surface station to communicate with each other through light pulses, RF or electric pulses. Here we show several instances of such a relay chain in the middle phase of our "combined scenario #1" and we test information transfer in both directions by triggering either the ground swarm or the base station with a flashlight pulse. The relay chain is formed by Lily robots by executing a special "shoaling algorithm" which is inspired by fish shoaling behavior. It is based on reactions to nearest neighbors sensed passively by photodiodes on the outer hull of the Lily robots. Reception of periodic blue-light blinks allows the robots to detect each other and to align/orient relative to the neighboring configuration. Thus the relay chain formation itself is almost communication-free, as the photodiodes and blinks could be easily replaced by a video camera and object detection. It is just passive sensing and interpretation of the local environment. The only communication act performed is the relaying of the RF pulse information, which was implemented similar to slime-mould amoebas' communication strategy.