Uploaded July 2015 | Updated September 2026, 1 week ago
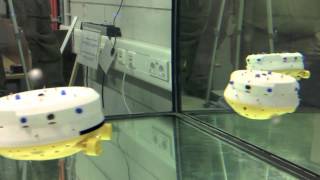
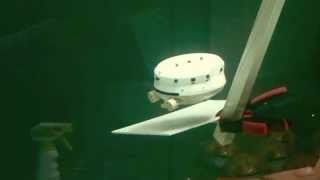
The Year of CoCoRo 28/52: This video uses a heterogeneous swarm of Lily robots, Jeff robots and a surrogate for the later-developed surface station. The search target was again a magnetic target in a fragmented habitat. The Jeff robot first autonomously searches for a magnetic target. When it finds the target it stops, switches on its vertical blue-light LEDs and also its red LEDs. This attracts some Lily robots browsing around near the surface. The Lily robots that pick up this signal from the ground stop and recruit other Lily robots by horizontal blue-light LEDs. This attracts even more Lily robots, establishing a positive feedback loop forming a growing aggregation of robots. Ultimately all Lily robots are aggregated at the target spot and also the one Lily robot that emulates the surface station is also recruited to the spot of the found target.
The Year of CoCoRo 28/52: This video uses a heterogeneous swarm of Lily robots, Jeff robots and a surrogate for the later-developed surface station. The search target was again a magnetic target in a fragmented habitat. The Jeff robot first autonomously searches for a magnetic target. When it finds the target it stops, switches on its vertical blue-light LEDs and also its red LEDs. This attracts some Lily robots browsing around near the surface. The Lily robots that pick up this signal from the ground stop and recruit other Lily robots by horizontal blue-light LEDs. This attracts even more Lily robots, establishing a positive feedback loop forming a growing aggregation of robots. Ultimately all Lily robots are aggregated at the target spot and also the one Lily robot that emulates the surface station is also recruited to the spot of the found target.