Uploaded August 2015 | Updated September 2026, 1 week ago
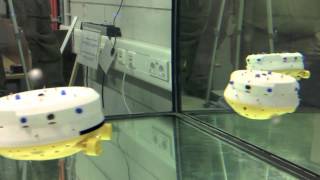
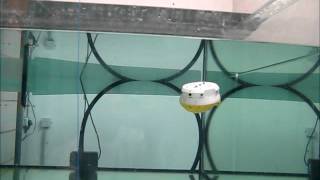
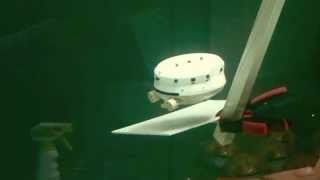
The Year of CoCoRo 35/52: In this video we show a set of experiments that investigate the capability of the relay chain (formed by Lily robots) to transmit (relay) information between two spatially separated places. At one of these places we trigger a special RF (radio frequency) pulse to be emitted by a robot. Neighboring robots that receive such a pulse will also send a similar pulse, this way they relay the signal along the chain. To have control over the directionality of the signal spreading, there is also a refractory period after each relaying act in which the robot is unreceptive for the relayed signal. This system is inspired by slime mold amoebas and giant honeybees and serves very well for the underwater communication purpose.
The Year of CoCoRo 35/52: In this video we show a set of experiments that investigate the capability of the relay chain (formed by Lily robots) to transmit (relay) information between two spatially separated places. At one of these places we trigger a special RF (radio frequency) pulse to be emitted by a robot. Neighboring robots that receive such a pulse will also send a similar pulse, this way they relay the signal along the chain. To have control over the directionality of the signal spreading, there is also a refractory period after each relaying act in which the robot is unreceptive for the relayed signal. This system is inspired by slime mold amoebas and giant honeybees and serves very well for the underwater communication purpose.