Uploaded August 2012 | Updated September 2026, 1 week ago
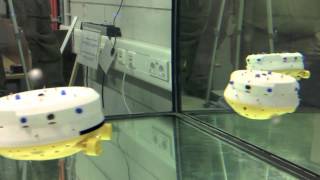
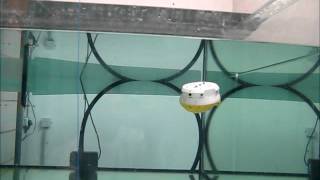
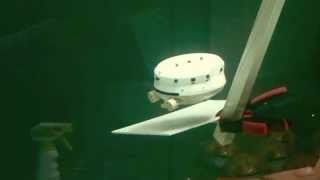
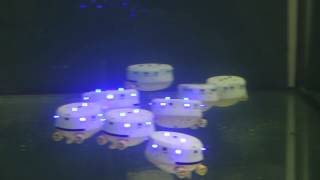
This video show a simulated scenario of the CoCoRo project:
First, the AUVs have to aggregate at a certain spot (a pit on the sea floor), using the bio-inspired BEECLUST algorithm.
While the AUVs are waiting, the AUVs then measure their swarm size, using an algorithm that was inspired by the firefly blinking behaviour.
Once the group of AUVs is big enough for the search swarm, these AUVs then rise until they are in the chemical plume that is amanating from a leaking barrel in the upper right corner on the sea floor.
Lastly, the AUVs use a special shoaling algorithm that enables them to collectively move uphill the chemical gradient and thus find the source.
Project homepage: http://cocoro.uni-graz.at
This video show a simulated scenario of the CoCoRo project:
First, the AUVs have to aggregate at a certain spot (a pit on the sea floor), using the bio-inspired BEECLUST algorithm.
While the AUVs are waiting, the AUVs then measure their swarm size, using an algorithm that was inspired by the firefly blinking behaviour.
Once the group of AUVs is big enough for the search swarm, these AUVs then rise until they are in the chemical plume that is amanating from a leaking barrel in the upper right corner on the sea floor.
Lastly, the AUVs use a special shoaling algorithm that enables them to collectively move uphill the chemical gradient and thus find the source.
Project homepage: http://cocoro.uni-graz.at