Uploaded July 2015 | Updated September 2026, 1 week ago
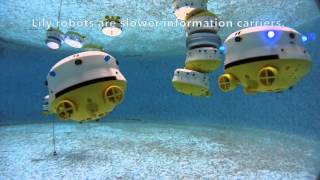
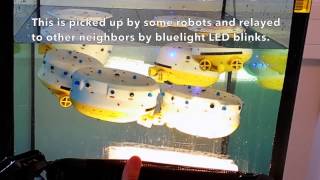
The Year of CoCoRo 30b/52: This is the second video of week #30 in "The Year of CoCoRo". While the video 30a has shown a computer animation that illustrates the different phases of the "combined scenario #1", this video here shows how this scenario was performed by real robots in the water. It is noteworthy that all phases of the scenario were executed in one single run, not split up into different experiments. This was important for us to demonstrate that with the modular algorithmic design of CoCoRo it is in fact possible to build up complex behavioral programs to solve complex tasks. So far in bio-inspired robotics and swarm robotics the world has either seen simple algorithms that made the robots perform simple tasks or complex scenarios achieved by very complex and specifically written software. To our knowledge this is the first time in swarm robotics that several very simple signal exchange patterns and behavioral responses triggered by simple signals achieved from the environment are combined to a still simple piece of code that allows the robot swarm to perform a very complex behavioral program. There is no global knowledge, no map, no ego-positioning, no image tracking, no computer vision acting in this autonomous swarm. It are just a few blue-light blinks, photoreceptors to receive such blinks, random-walk programs, communication-free shoaling-behavior for the relay chain, radio-frequency pulsing and a simple robot-internal compass. There is nothing more. This is how swarm robotics should be from our point of view: Simple, robust, flexible, scalable and, most important, working!
The Year of CoCoRo 30b/52: This is the second video of week #30 in "The Year of CoCoRo". While the video 30a has shown a computer animation that illustrates the different phases of the "combined scenario #1", this video here shows how this scenario was performed by real robots in the water. It is noteworthy that all phases of the scenario were executed in one single run, not split up into different experiments. This was important for us to demonstrate that with the modular algorithmic design of CoCoRo it is in fact possible to build up complex behavioral programs to solve complex tasks. So far in bio-inspired robotics and swarm robotics the world has either seen simple algorithms that made the robots perform simple tasks or complex scenarios achieved by very complex and specifically written software. To our knowledge this is the first time in swarm robotics that several very simple signal exchange patterns and behavioral responses triggered by simple signals achieved from the environment are combined to a still simple piece of code that allows the robot swarm to perform a very complex behavioral program. There is no global knowledge, no map, no ego-positioning, no image tracking, no computer vision acting in this autonomous swarm. It are just a few blue-light blinks, photoreceptors to receive such blinks, random-walk programs, communication-free shoaling-behavior for the relay chain, radio-frequency pulsing and a simple robot-internal compass. There is nothing more. This is how swarm robotics should be from our point of view: Simple, robust, flexible, scalable and, most important, working!