Uploaded February 2015 | Updated September 2026, 1 week ago
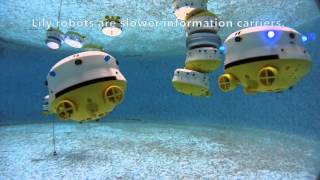
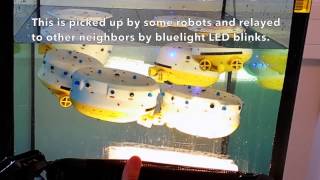
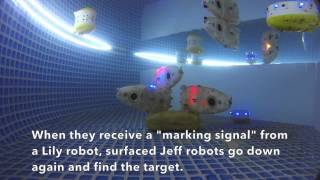
The Year of CoCoRo 08/52: A swarm of Lily robots can form a coherent group by exchanging light pulses in a slime-mold inspired way among the group members. By modulating the frequency of these signals the group can alter the path of the emerging blinking wave to turn the whole group towards the aggregation target. Such a target can be any form of gradient emitting source, regardless of the type of the emitted signal. We demonstrate this here by using a light source as a target.
The Year of CoCoRo 08/52: A swarm of Lily robots can form a coherent group by exchanging light pulses in a slime-mold inspired way among the group members. By modulating the frequency of these signals the group can alter the path of the emerging blinking wave to turn the whole group towards the aggregation target. Such a target can be any form of gradient emitting source, regardless of the type of the emitted signal. We demonstrate this here by using a light source as a target.