Uploaded September 2015 | Updated September 2026, 1 week ago
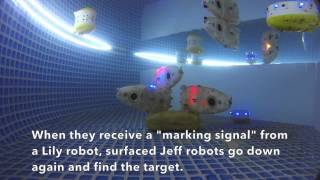
The Year of CoCoRo 37B/52: This video shows several runs of the "combined scenario #2", which is a collective search scenario. In a fragmented habitat a swarm of Jeff robots (on the ground) and Lily robots (information carriers at all depths) and a simple surface station -- we used a special Lily robot as a surrogate here -- cooperate to identify the compartment of the habitat that holds the magnetic search target. The robots perform the algorithms/behaviors described in the computer animation we also published this week (movie 37A/52 on The Year of CoCoRo). Initially each one of the four environmental compartments holds one searching Jeff robot on the ground. At the end of the run, three of these robots are located in the compartment with the target, many Lily robots and also the surrogate of the surface station are aggregated there. The one Jeff robot that did not reach the target compartment was informed about the finding of the other Jeff robots but for mechanical reasons it could not change its depth to overcome the compartmental wall, although it tried several times, as indicated by the green LED signals it shows from time to time. This is how it works in swarm robotics. There are always some robots not performing well. The good news is that this is part of the game in a swarm system: They stay functional as a collective even though some of the swarm members malfunction.
Music: freemusicarchive.org/music/Charles_Atlas/To_the_Dust_From_Man_You_Came_and_To_Man_You_Shall_Return
License for music: creativecommons.org/licenses/by-nc-sa/3.0
The Year of CoCoRo 37B/52: This video shows several runs of the "combined scenario #2", which is a collective search scenario. In a fragmented habitat a swarm of Jeff robots (on the ground) and Lily robots (information carriers at all depths) and a simple surface station -- we used a special Lily robot as a surrogate here -- cooperate to identify the compartment of the habitat that holds the magnetic search target. The robots perform the algorithms/behaviors described in the computer animation we also published this week (movie 37A/52 on The Year of CoCoRo). Initially each one of the four environmental compartments holds one searching Jeff robot on the ground. At the end of the run, three of these robots are located in the compartment with the target, many Lily robots and also the surrogate of the surface station are aggregated there. The one Jeff robot that did not reach the target compartment was informed about the finding of the other Jeff robots but for mechanical reasons it could not change its depth to overcome the compartmental wall, although it tried several times, as indicated by the green LED signals it shows from time to time. This is how it works in swarm robotics. There are always some robots not performing well. The good news is that this is part of the game in a swarm system: They stay functional as a collective even though some of the swarm members malfunction.
Music: freemusicarchive.org/music/Charles_Atlas/To_the_Dust_From_Man_You_Came_and_To_Man_You_Shall_Return
License for music: creativecommons.org/licenses/by-nc-sa/3.0