Uploaded October 2015 | Updated September 2026, 1 week ago
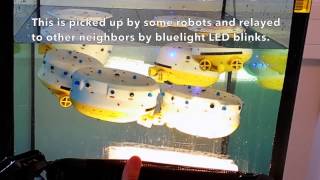
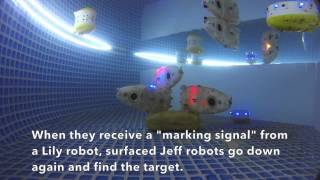
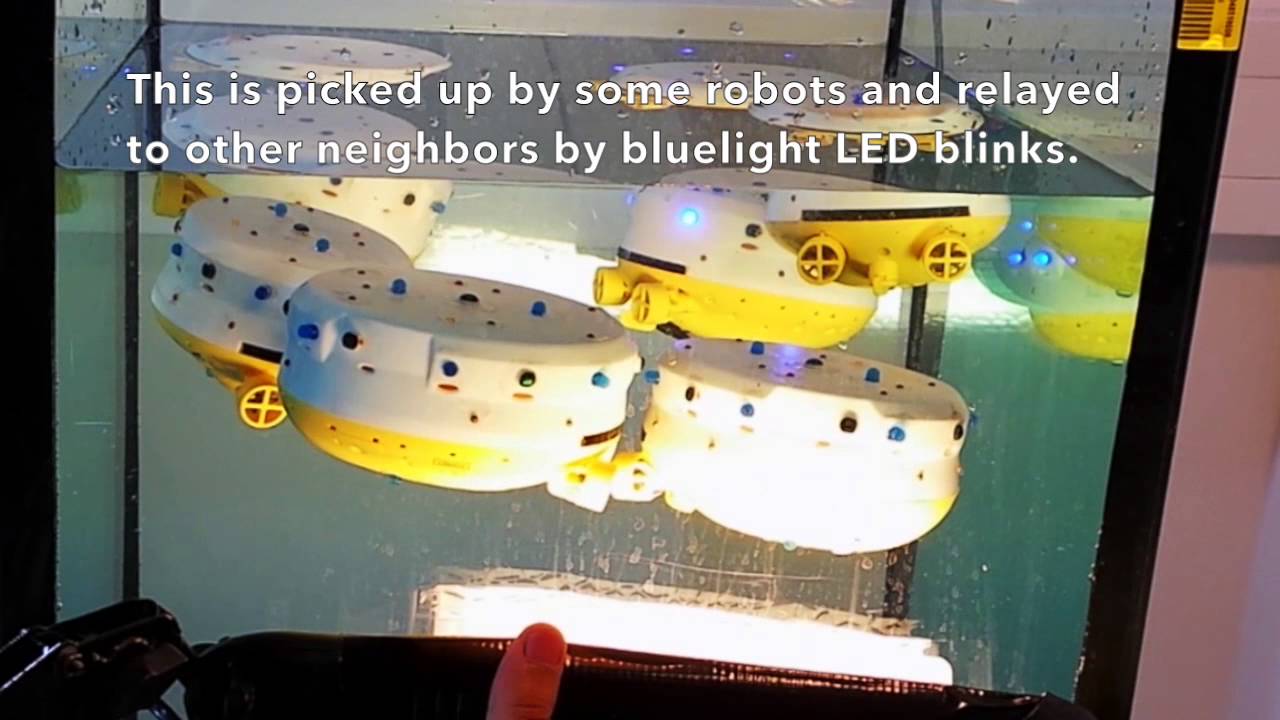
The Year of CoCoRo 40/52: Last week we have already introduced the "social inhibition algorithm" we developed for our CoCoRo robot swarm. This is an algorithm for regulating division of labour inspired by the self-organized regulation of physiological age in honeybee colonies. The video this week explains the mechanisms used in the algorithm in more detail and shows our experiments with swarms of robots in a vertical aquarium. The robots regulate an internal variable X via interactions with other robots and split the swarm into 3 different cohorts allocating themselves at different depths in the aquarium. We add and remove robots to the swarm in the aquarium and their regulation of the internal variable X leads to automatic rearrangement in the swarm such that there is always an equal number of robots at each depth. We also add sources of interest which are special robots or external lights at different depth layers and the swarm rearranges in a way that more robots are attracted in these especially interesting depths. The algorithm shown here is promising due to its ability to automatically rearrange the robots to meet different demands based only on local interactions. This makes it interesting for being used in large scale scenarios where several sub-groups of the swarm are needed to act in different depth levels performing different tasks within the swarm.
The Year of CoCoRo 40/52: Last week we have already introduced the "social inhibition algorithm" we developed for our CoCoRo robot swarm. This is an algorithm for regulating division of labour inspired by the self-organized regulation of physiological age in honeybee colonies. The video this week explains the mechanisms used in the algorithm in more detail and shows our experiments with swarms of robots in a vertical aquarium. The robots regulate an internal variable X via interactions with other robots and split the swarm into 3 different cohorts allocating themselves at different depths in the aquarium. We add and remove robots to the swarm in the aquarium and their regulation of the internal variable X leads to automatic rearrangement in the swarm such that there is always an equal number of robots at each depth. We also add sources of interest which are special robots or external lights at different depth layers and the swarm rearranges in a way that more robots are attracted in these especially interesting depths. The algorithm shown here is promising due to its ability to automatically rearrange the robots to meet different demands based only on local interactions. This makes it interesting for being used in large scale scenarios where several sub-groups of the swarm are needed to act in different depth levels performing different tasks within the swarm.