Uploaded May 2009 | Updated September 2026, 1 week ago
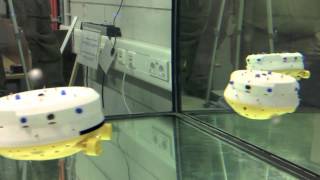
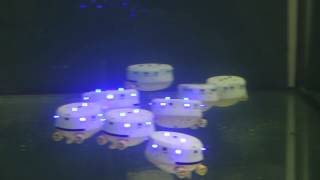
This is a simulation of a robot swarm using only short-range distance sensors to achieve emergent flocking. The yellow line shows the movment of the center of mass of the aggregated swarm.
Developed by Christoph Möslinger at the Artificial Life Lab of the Department of Zoology, Karl-Franzens University Graz, Austria.
Programs used: NetLogo.
This is a simulation of a robot swarm using only short-range distance sensors to achieve emergent flocking. The yellow line shows the movment of the center of mass of the aggregated swarm.
Developed by Christoph Möslinger at the Artificial Life Lab of the Department of Zoology, Karl-Franzens University Graz, Austria.
Programs used: NetLogo.