Uploaded November 2011 | Updated September 2026, 1 week ago
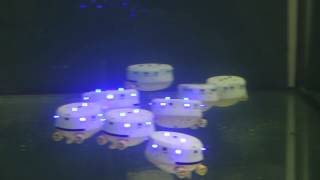
Time lapse recording (15 x) of a swarm of 15 Jasmine robots employing the bio inspired BEECLUST algorithm, navigating through a dynamic complex light gradient in an arena (150 x 100 cm). The lighting is controlled by two lamps above the left and right edge of the arena. The experiment is divided into four phases with different lighting conditions, each of which lasting for 3 min in realtime (12 s in time lapse): 1: left lamp off, right lamp dim; 2: left lamp bright, right lamp dim; 3: left lamp dim, right lamp bright; 4: left lamp dim, right lamp off. When one lamp is off, the dim lamp appears as bright as the bright lamp when the other lamp is dim. This is a camera artifact which does not affect the robots. If a robot detects another robot at a range of 5 cm or less, it stops and rests for a period proportional to the local light intensity. This behaviour is inspired by honeybees, which aggregate at optimal areas using a comparable mechanism with local temperature as a clue. When available, bright areas induce larger aggregations of robots. Dim areas are less attractive and only induce small aggregations, especially when competing with a bright area.
Time lapse recording (15 x) of a swarm of 15 Jasmine robots employing the bio inspired BEECLUST algorithm, navigating through a dynamic complex light gradient in an arena (150 x 100 cm). The lighting is controlled by two lamps above the left and right edge of the arena. The experiment is divided into four phases with different lighting conditions, each of which lasting for 3 min in realtime (12 s in time lapse): 1: left lamp off, right lamp dim; 2: left lamp bright, right lamp dim; 3: left lamp dim, right lamp bright; 4: left lamp dim, right lamp off. When one lamp is off, the dim lamp appears as bright as the bright lamp when the other lamp is dim. This is a camera artifact which does not affect the robots. If a robot detects another robot at a range of 5 cm or less, it stops and rests for a period proportional to the local light intensity. This behaviour is inspired by honeybees, which aggregate at optimal areas using a comparable mechanism with local temperature as a clue. When available, bright areas induce larger aggregations of robots. Dim areas are less attractive and only induce small aggregations, especially when competing with a bright area.